Andra Keay, director of Silicon Valley Robotics, talks with Going Direct host Jordan about human-centered robot design, commercialization, and her five ethical laws of robotics.
Shiao-Ju, who works on tactile sensing and related algorithms at Sharpa, presents at GTC 2026 on using tactile AI for high-degree-of-freedom dexterous manipulation.
Max Simchowitz, a Carnegie Mellon professor who studies machine learning theory and interactive, sequential problems, explains generative control and action chunking at a Carnegie Mellon Robotics Institute seminar.
Claire Zau of ZAUEY visits Sunday Robotics with CEO Tony Zhao and head of product Camila to discuss Memo, a household robot that learns chores from human demonstrations.
Skyentific’s host explains how he moved a simulated bipedal robot into physical walking using NVIDIA Isaac Lab, a Jetson Orin Nano Super, and iterative hardware debugging.
He Wang, Founder and CTO at Galbot, presents at the Humanoids Summit on building general-purpose robots with synthetic data, learned control, and sim-to-real methods.
Tatsuya Ogata, a Waseda University professor and chairman of a Japanese robotics association, discusses Japan’s work on humanoids and physical AI at the Humanoids Summit.
Chaoyi Li of Booster Robotics presents at Humanoids Summit on building affordable humanoid platforms and a developer ecosystem to expand practical uses for robots.
Ryan Saavedra, CEO and founder of Unlimited Bionics, explains how the company designs and prices bionic hands for people with limb loss and humanoid robots, speaking at the Humanoids Summit.
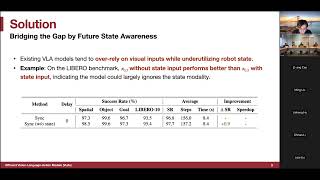
Jiaming Tang, an MIT PhD student researching efficient robotics and large models, presents VLASH at the Robot Perception and Learning Lab, explaining how future-state-aware asynchronous inference can make vision-language-action policies respond faster.
Harry Asada, professor at MIT, discusses robotics research, human-assistive robots, and using Koopman operators with model predictive control at Purdue ICON’s Spring 2026 seminar.
Yinhuai Wang, a second-year PhD student at HKU supervised by Professor Ping Tan, presents HumanX, a method for learning humanoid interaction skills from human videos at the Robot Perception and Learning Lab.
Elvis Nava, co-founder and CTO of Mimic Robotics, discusses dexterous robot hands and learning-based manipulation with host Devang on The Humanoid Hub.
Daniele Pucci, CEO of Generative Bionics, discusses the GENE.01 humanoid and the company’s approach to industrial applications with the host of the Humanoid Leaders series.
Rob Cochran, co-founder of Fauna Robotics, discusses the Sprout developer robot with Automated host Brian Heater, covering its design, customers, software, and path toward broader use.
Stone Tao, a PhD student at the University of California, San Diego, presents simulation-integrated robot learning at the GRASP Lab, covering sim-to-real cable routing and simulation software design.
Wenlong Huang, a Stanford computer science PhD candidate, presents his work on 3D world models for robotic manipulation at the Robot Perception and Learning Lab.
Rob Cochrane, CEO and co-founder of Fauna Robotics, introduces Sprout to NBC News anchor Tom Llamas on Top Story and discusses the robot’s current abilities, safety, and possible future in homes.
Zuan and Shouting Drew, Project Instinct coauthors working on robotics hardware and learning algorithms, discuss humanoid whole-body control and their open-source research toolkit with RoboPapers host Jaffy.
Florian Shkurti, a University of Toronto researcher whose work is also discussed at Ai2, presents research on evaluating and stress-testing robotics policies at the 2026 Winter Robotics Colloquium, hosted by Abhishek Gupta.
Saman Farid, founder and CEO of Formic, talks with Jordan on Going Direct about deploying robots in American factories, the barriers to adoption, and how robotics as a service can help manufacturers expand production.
A Zoom Vantage presenter discusses South Korea’s robotics landscape, from humanoid systems and research platforms to robots used in industry and public life.
David Held, associate professor at Carnegie Mellon University and head of the RPAD Lab, presents research on precise, generalizable robot manipulation at a GRASP on Robotics seminar hosted by a Penn faculty member.
Hongyu Lee, a PhD student at Brown, and Ju, a research scientist at the AI Institute, discuss NovaFlow, their zero-shot robot manipulation work, with the RoboPapers host and audience.
Briefs summarise talks and interviews; timestamps open the video at that moment. Claims in a talk are the speaker's own.