Ruining Li, an Oxford Visual Geometry Group PhD student and Amazon FAR research intern, discusses data-driven methods for creating physically stable and articulated 3D assets for robotics with the Robot Perception and Learning Lab.
Yuke Zhu, professor at the University of Texas at Austin and humanoid robotics lead at NVIDIA, presents research on generalist humanoid robots at a keynote session in Vienna.
Simar Kareer, a robotics researcher at Physical Intelligence, discusses learning robot skills from embodied human data at a talk hosted by the Robot Perception and Learning Lab.
MIT postdoc Congyue Deng, speaking for the Robot Perception and Learning Lab, discusses how visual and action representations can help robots generalize across objects and tasks.
Fangchen Liu, a research scientist at Google DeepMind, presents work on scalable, generalizable robot learning at the Robot Perception and Learning Lab.
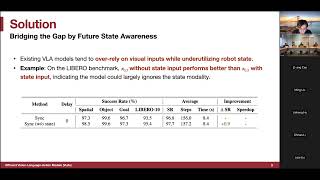
Jiaming Tang, an MIT PhD student researching efficient robotics and large models, presents VLASH at the Robot Perception and Learning Lab, explaining how future-state-aware asynchronous inference can make vision-language-action policies respond faster.
Yinhuai Wang, a second-year PhD student at HKU supervised by Professor Ping Tan, presents HumanX, a method for learning humanoid interaction skills from human videos at the Robot Perception and Learning Lab.
Wenlong Huang, a Stanford computer science PhD candidate, presents his work on 3D world models for robotic manipulation at the Robot Perception and Learning Lab.
Anirudha Majumdar, associate professor at Princeton University and research scientist on Google DeepMind’s Robotics Safety and Alignment team, discusses action-conditioned video models for robot evaluation, training, and planning at a Robot Perception and Learning Lab talk.
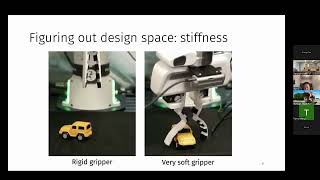
Dr. Yifan Hou, a postdoctoral researcher at Stanford’s REAL Lab, discusses methods for making robot manipulation more reliable in a talk hosted by the Robot Perception and Learning Lab.
A researcher from the Robot Perception and Learning Lab presents at CoRL 2023 on building generalist robots through scalable algorithms, continuous data collection, and versatile humanoid hardware.
Briefs summarise talks and interviews; timestamps open the video at that moment. Claims in a talk are the speaker's own.