Apollo vs Figure
Apollo is a humanoid robot by Apptronik (United States); Figure comes from Figure AI (United States). Apollo is taller at 173 cm, against 168 cm for Figure. Apollo is heavier: 72 kg versus 60 kg for Figure. Apollo has more degrees of freedom (71 against 30). Apollo is in pilot deployments, while Figure is a prototype. Listed prices: $50,000 for Apollo and $130,000 for Figure.
Add up to two more robots or show only the rows that differ.
| Spec | 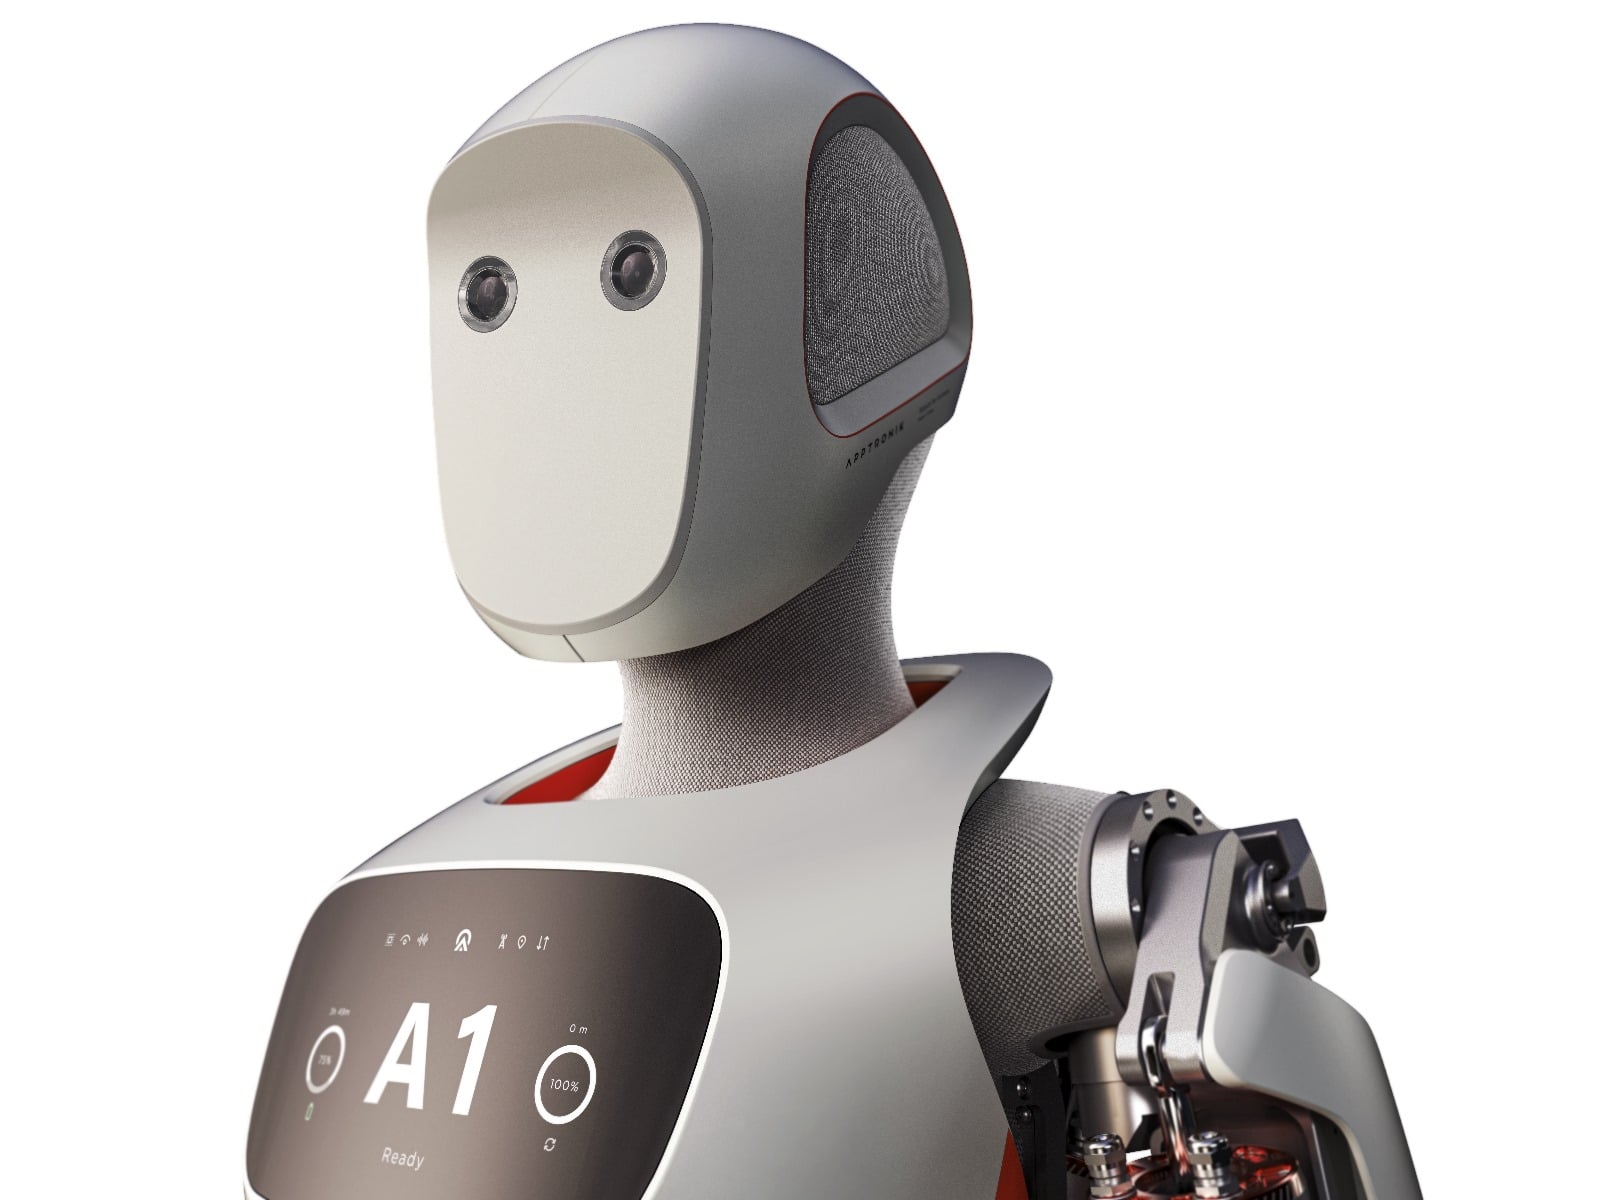  🇺🇸 United StatesPilot | 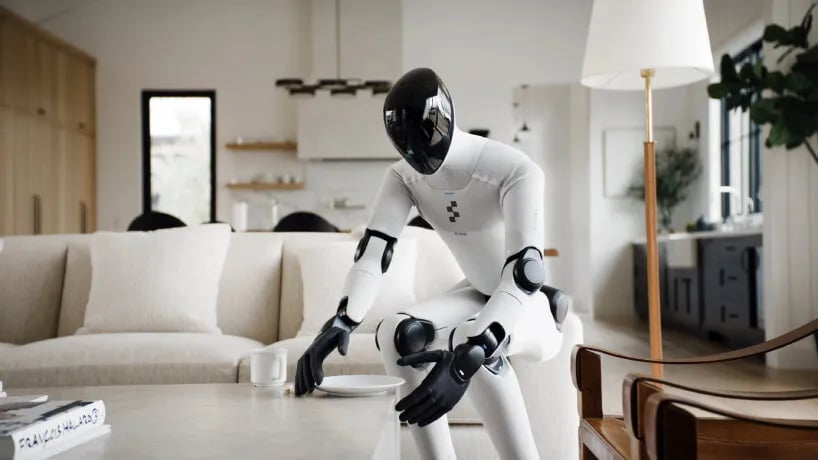  🇺🇸 United StatesPrototype |
|---|---|---|
| Overview | ||
| Year | ||
| Year | 2023 | 2025 |
| Body | ||
| Height | ||
| Height | 173 cm | 168 cm |
| Weight | ||
| Weight | 72 kg | 60 kg |
| Degrees of freedom | ||
| Degrees of freedom | 71 | 30 |
| DoF (hands) | ||
| DoF (hands) | - | 20 |
| Fingers | ||
| Fingers | - | 10 |
| Structural material | ||
| Structural material | - | Battery enclosure uses stamped steel, die-cast aluminum, and structural adhesives |
| Motion | ||
| Max speed | ||
| Max speed | 3.4 km/h | 4.3 km/h |
| Walking speed | ||
| Walking speed | 3.4 km/h | 4.3 km/h |
| Strength | ||
| Strength | 24.9 kg | 20 kg |
| Runtime | ||
| Runtime | 4 h | 5 h |
| Motor tech | ||
| Motor tech | - | Frameless BLDC-motors |
| Gear tech | ||
| Gear tech | - | Strain-wave (harmonic) and/or cycloidal |
| Sensing & Compute | ||
| CPU / GPU | ||
| CPU / GPU | - | Helix runs entirely on-board on dual low-power embedded GPUs |
| Operating system | ||
| Operating system | - | Ubuntu Linux (LTS) + RT-komponenter |
| LLM integration | ||
| LLM integration | - | Helix uses an open-source, open-weight VLM for high-level reasoning |
| Camera | ||
| Camera | - | 03 introduces a new vision system with 2× frame rate, ¼ latency, and +60% FoV per camera, plus palm cameras in each hand. |
| Connectivity | ||
| Connectivity | - | 10 Gbps mmWave data offload; wireless inductive charging and data offload |
| Latency (glass → action) | ||
| Latency (glass → action) | - | No numeric “glass-to-action” latency published. Site notes ¼ camera latency vs. prior architecture and 200 Hz low-level control |
| Safety & Market | ||
| Safe with humans | ||
| Safe with humans | Designed for friendly interaction and safety; uses perimeter zone and impact zone behavior to create a safe working environment. | - |
| Primary market | ||
| Primary market | Warehouses and manufacturing plants | Home service, Industries |
| Country | ||
| Country | United States | United States |
| Availability | ||
| Availability | Pilot | Prototype |
| Price | ||
| Price | $ 50 000 | $ 130 000 |
| Verified facts | ||
| Deployments | ||
| Deployments | - | 1 |
| Production records | ||
| Production records | - | 1 |
| All reviewed facts | ||
| All reviewed facts | - | 11 |
Counts of reviewed facts with sources. Open a robot page to see each fact and its links.
More comparisons
 Apollo vs OptimusApptronik · Tesla
 Apollo vs AtlasApptronik · Boston Dynamics
 Apollo vs Walker S1Apptronik · UBTECH Robotics
 Apollo vs DigitApptronik · Agility Robotics
 Apollo vs Expedition A3Apptronik · AGIBOT
 A2 vs ApolloAGIBOT · Apptronik
- Figure vs OptimusFigure AI · Tesla
 Figure vs IRONFigure AI · XPENG