Berkeley RDI· Aug 9, 2026
Panel: Robotics & World Models
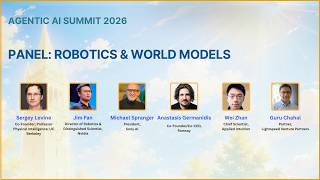
Guru Chahal moderates Berkeley RDI panelists Anastasis Germanidis, Jim Fan, Sergey Levine, Michael Spranger, and Wei Zhan on world models, robotics data, simulation, and commercial deployment.
Jim Fan, who leads NVIDIA’s embodied autonomy research group, presents at Sequoia Capital on how robotics could adapt AI’s scaling playbook through world action models, human data, and simulated environments.
Fan maps language model progress from GPT-3 pre-training through instruction tuning, reinforcement learning, and automated research. He proposes a similar path for robotics: predict future physical states, tune models toward useful robot actions, then use reinforcement learning to improve performance.
Fan argues that vision-language-action models devote too much capacity to language and are better at representing objects than physical behavior. He points to video models that appear to learn properties such as gravity and buoyancy, then introduces Dreamer, which predicts future scenes alongside motor commands. He calls this broader approach world action models, designed for open-ended instructions.
Fan says teleoperation is constrained by robot availability and estimates that practical collection often amounts to about three hours per robot each day. He describes UMI and Dex-UMI interfaces that let people collect manipulation data directly, then presents Ego-Exo, pre-trained on 21,000 hours of first-person human video with no robot data. Its action tuning uses 50 hours of motion-capture data and four hours of teleoperation; Fan reports a scaling relationship between video hours and dexterity performance.
Fan proposes combining a small number of real robot stations with scanned objects in physics simulators and learned video-based simulators. DreamDojo takes robot actions and generates visual frames and sensor states, without relying on hand-coded physics equations or graphics engines. Fan’s proposed system uses compute across these environments to increase the data available for robot learning.
Fan names three goals: robots that match human performance across varied tasks, fleets controllable through software interfaces, and robots that can research and build improved successors. He imagines applications including lights-out factories and automated wet labs. He predicts the broader robotics end game could arrive by 2040.
Briefs summarise talks and interviews; timestamps open the video at that moment. Claims in a talk are the speaker's own.
Guru Chahal moderates Berkeley RDI panelists Anastasis Germanidis, Jim Fan, Sergey Levine, Michael Spranger, and Wei Zhan on world models, robotics data, simulation, and commercial deployment.
NVIDIA founder and CEO Jensen Huang presents the company’s AI strategy and product announcements at GTC Berlin, with European partners and customers.
NVIDIA CEO Jensen Huang discusses Europe’s AI economy, NVIDIA’s AI infrastructure and agent platforms, and physical AI at GTC Berlin, with examples from European industry and NVIDIA partners.
The host and main speaker from Robotics Central explains Kawasaki’s staged plan to deploy Kaleido humanoid robots, and how Japan’s AI funding, Nvidia computing, and human remote operators fit into that effort.
Amulia Vishban, founder of Techable Ventures, discusses investing in physical AI with Dominic Madori Davis on TechCrunch’s Equity podcast.
Les Carpus, global head of physical AI for NVIDIA’s Inception program, discusses robotics startups and the path to a ChatGPT moment with TechCrunch reporter Tim at Disrupt 2026.