OH
ORCA Hand / Soft Robotics Lab (ETH Zürich)
Robots
 ORCA Hand / Soft Robotics Lab (ETH Zürich)
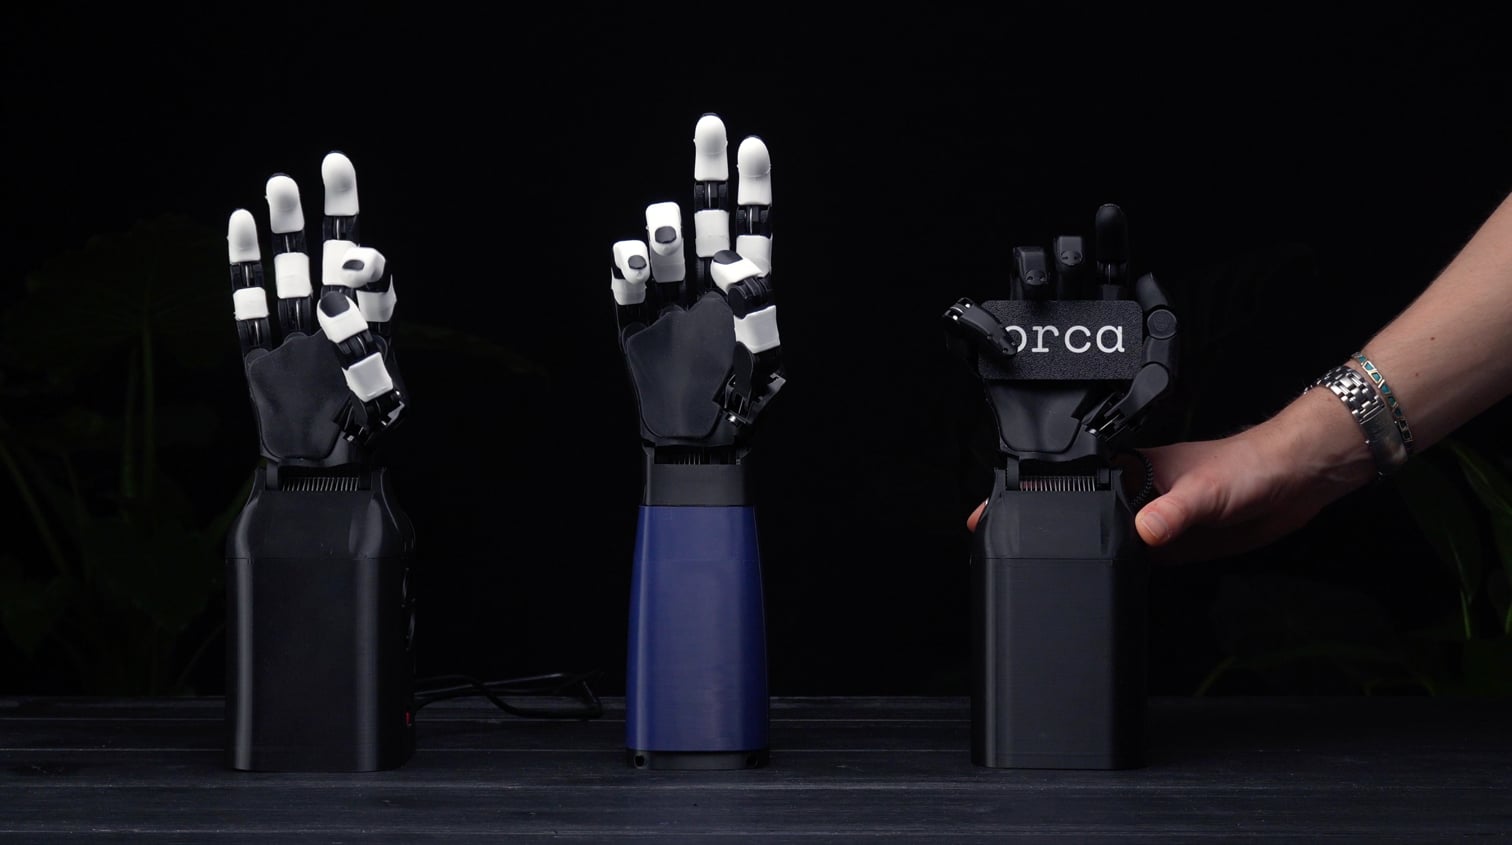
OrcaHand Lite
Soft robotic hand for manipulation and integration in robotics research and applications. It weighs 0.7 kg and has 9 DoF.
🇨🇭SwitzerlandCommercial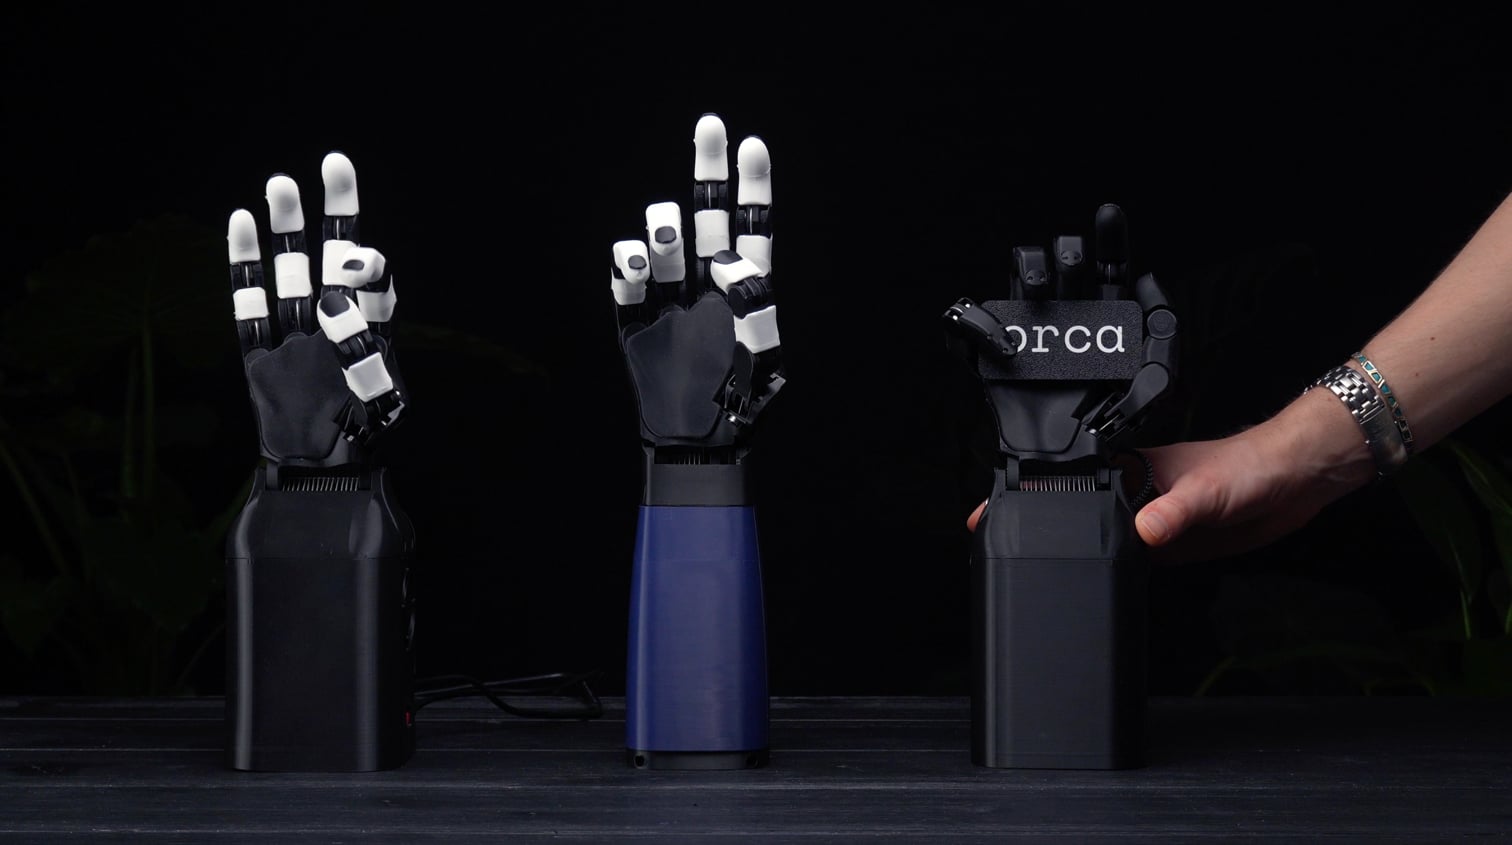 ORCA Hand / Soft Robotics Lab (ETH Zürich)
OrcaHand Touch
Tactile-enabled robotic hand for precise, adaptive manipulation in robotics research and advanced interaction tasks.
🇨🇭SwitzerlandCommercial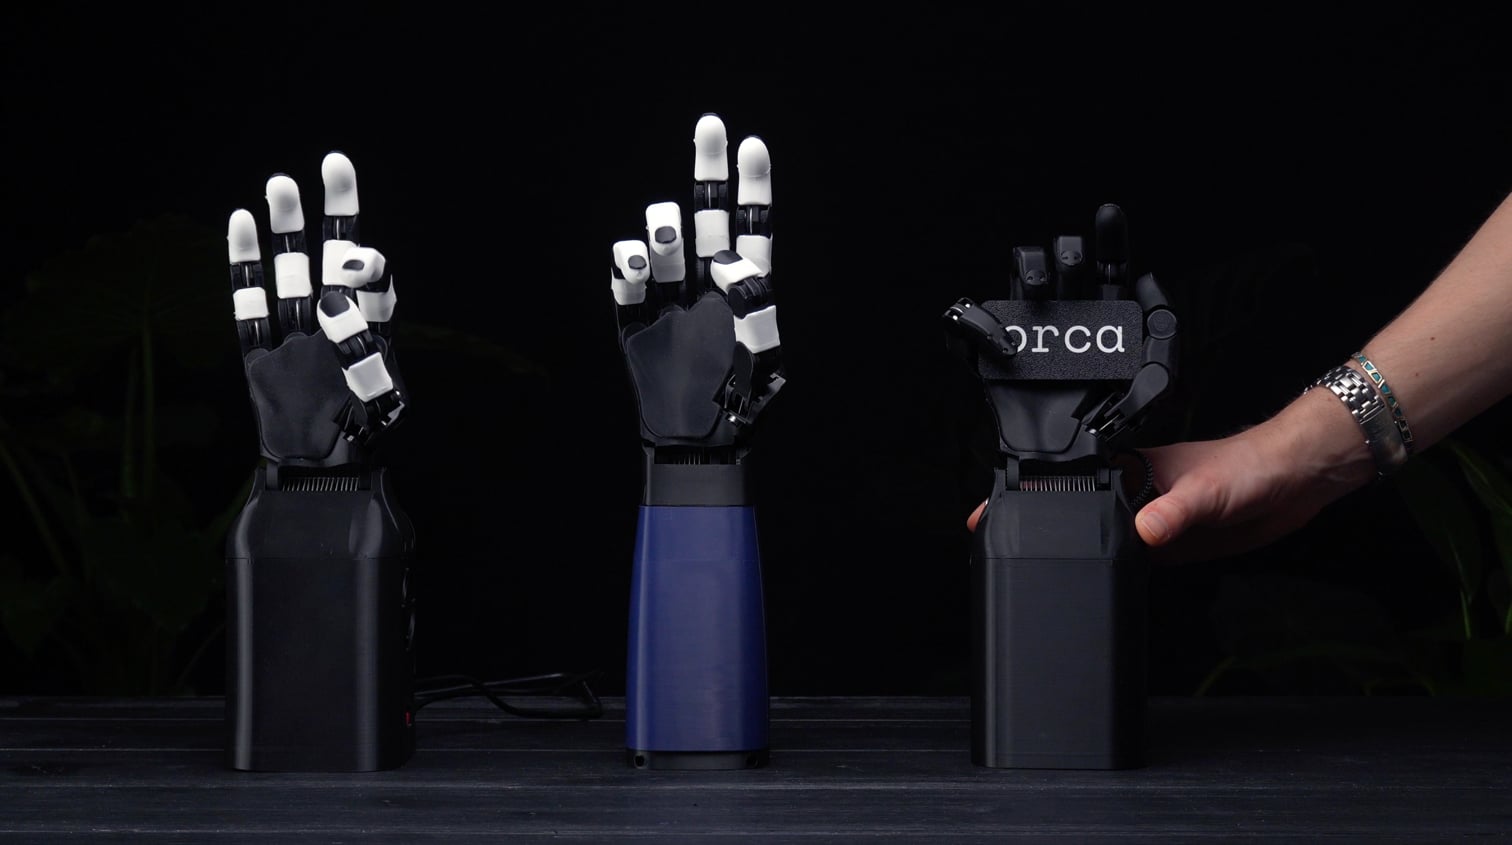 ORCA Hand / Soft Robotics Lab (ETH Zürich)
ORCA v1
Open-source robotic hand with a tendon-driven structure and 17 active degrees of freedom. It is used for research, education, and creative robotics projects.
🇨🇭SwitzerlandCommercial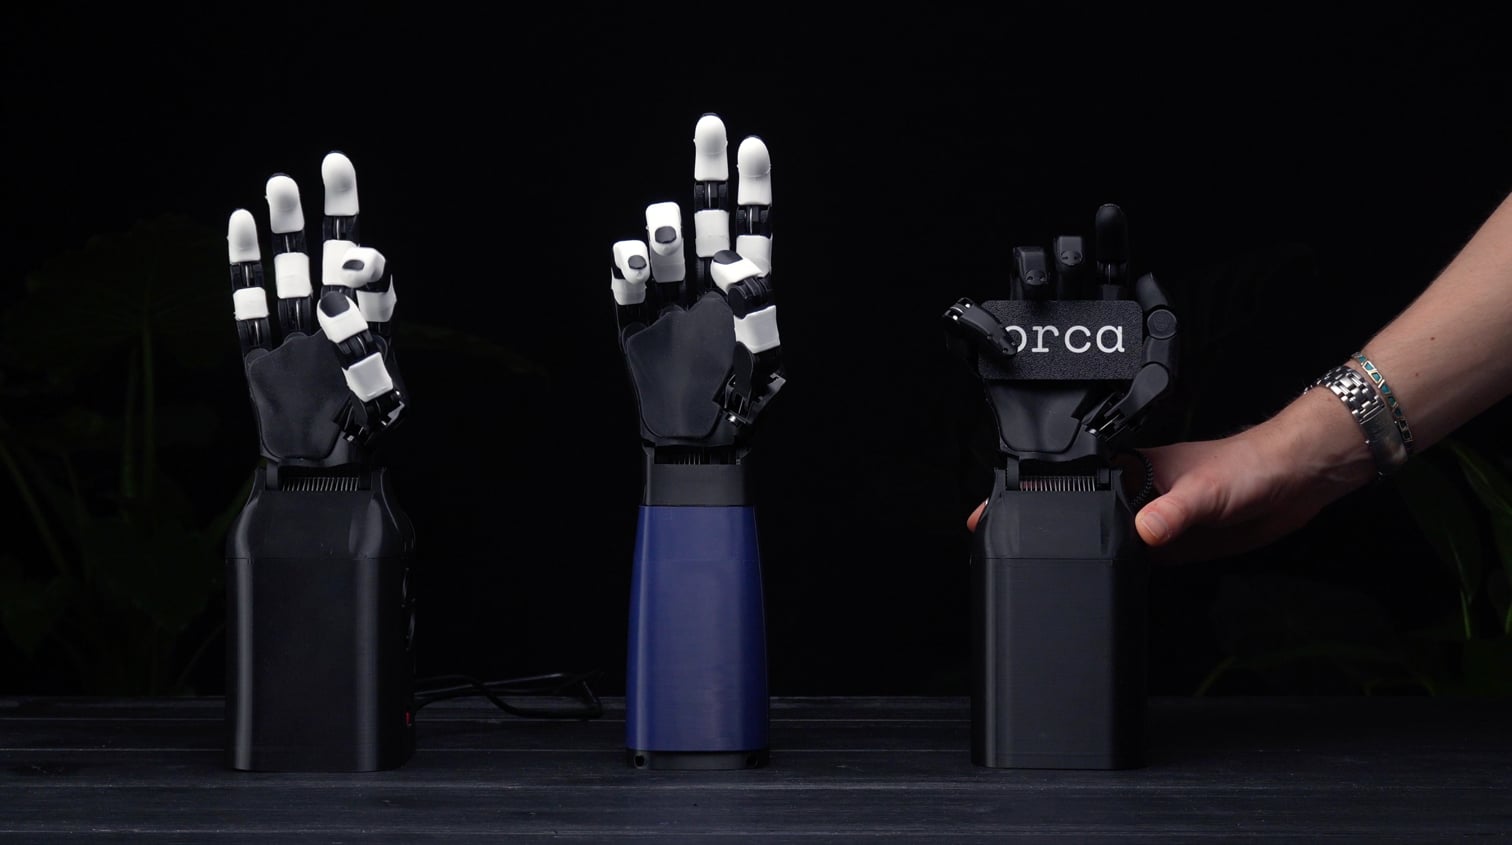 ORCA Hand / Soft Robotics Lab (ETH Zürich)
OrcaHand
Human-like robotic hand for dexterous manipulation in robotics research.
🇨🇭SwitzerlandCommercial