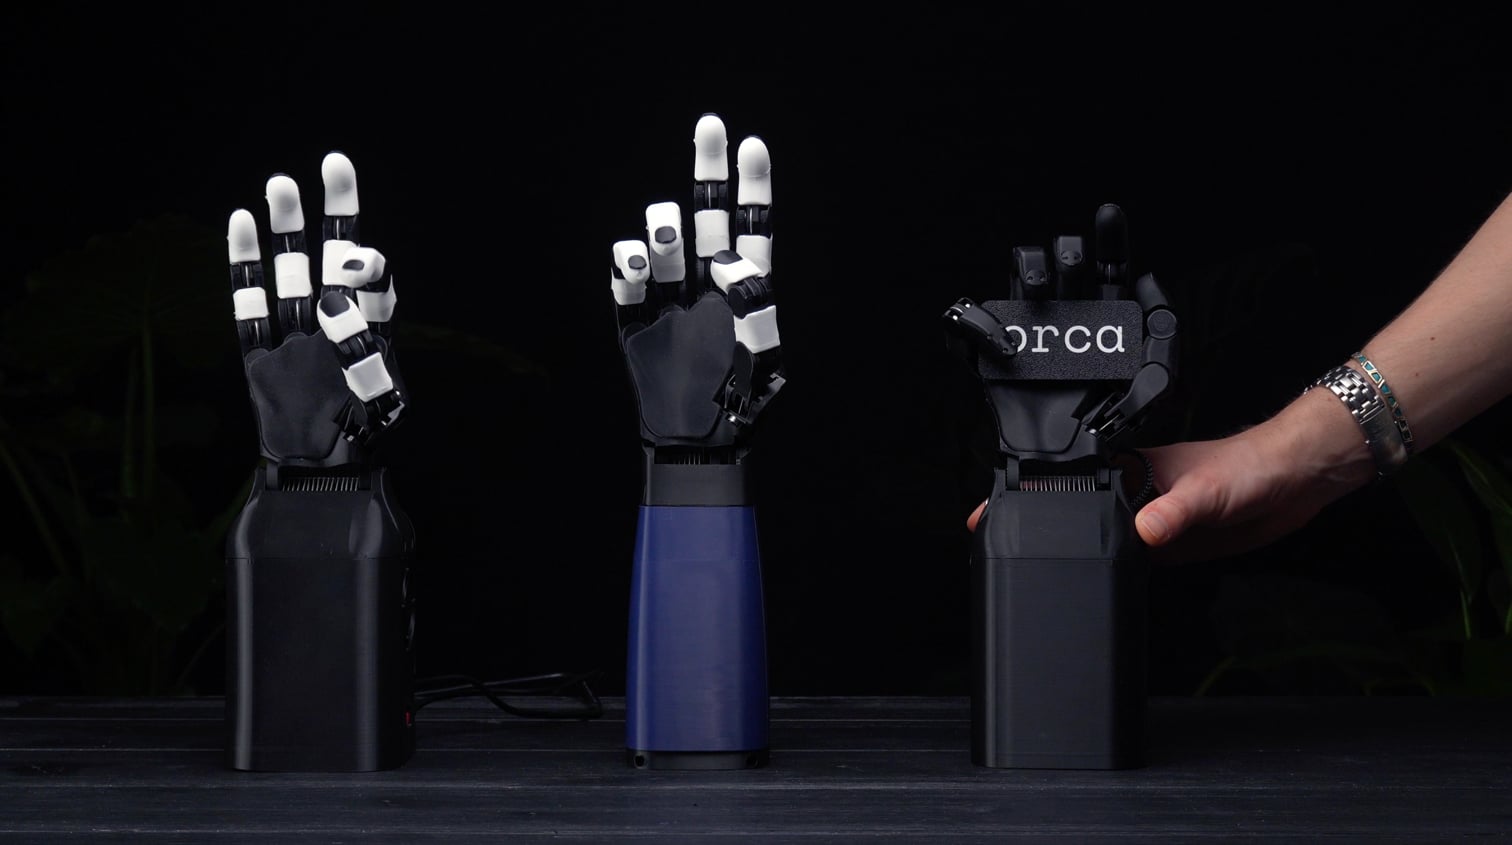
OrcaHand Touch
Commercial$6,100
Tactile-enabled robotic hand for precise, adaptive manipulation in robotics research and advanced interaction tasks.
- Weight
- 1.2 kg
- Strength
- 7 kg
About
OrcaHand Touch is a tactile-enabled robotic hand associated with research at ETH Zürich's Soft Robotics Lab. It was developed for manipulation research that requires both dexterous hand motion and tactile feedback, with an emphasis on precise, adaptive interaction with objects. I do not have enough reliable information to assign a specific launch year or end year.
Available information suggests it belongs to the ORCA Hand family and was presented as a research platform rather than a mass-produced commercial product. Its role is to support experiments in tactile sensing, grasping, and adaptive manipulation in academic robotics settings. Beyond that, I do not have verified details on a formal release or discontinuation timeline.
Specifications
Body
- Weight
- 1.2 kg
- DoF (hands)
- 17
- Fingers
- 5
- Structural material
- 3D-printed components with silicone skin for compliant contact
- Size
- Human-hand sized, anthropomorphic design
- Shipping size
- Human-hand sized, anthropomorphic design
Motion
- Strength
- 7 kg
- Motor tech
- Dynamixel XC330-T288 + XC430-T240BB / Feetech HL-3915 + HL-3930
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- robotics research and advanced interaction tasks
- Country
- Switzerland
- Availability
- Commercial
- Price
- $ 6 100