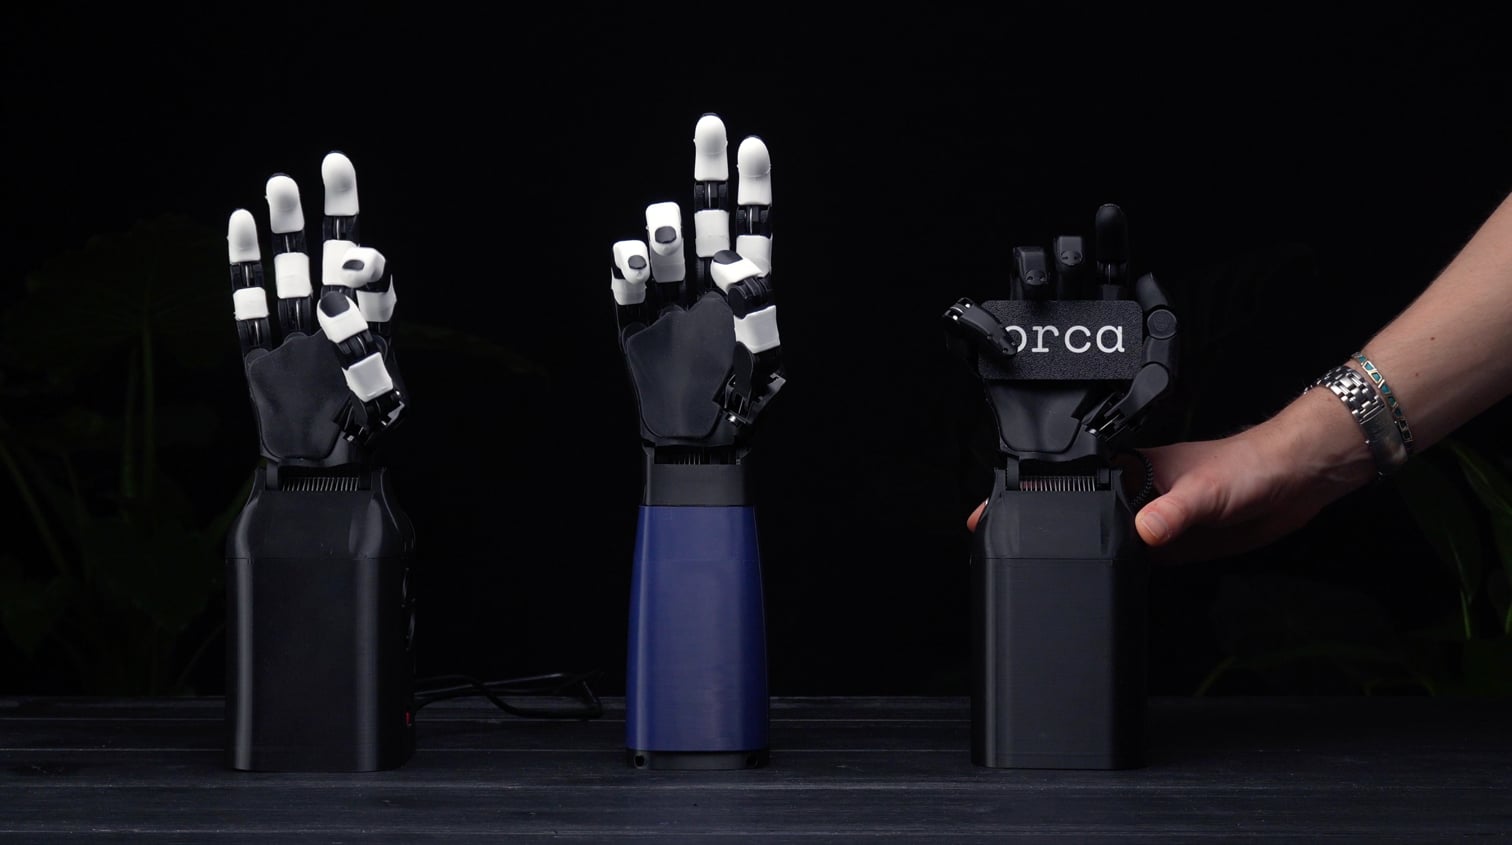
OrcaHand
Commercial$3,500
Human-like robotic hand for dexterous manipulation in robotics research.
- Weight
- 1.2 kg
- Degrees of freedom
- 17
- Strength
- 5 kg
About
OrcaHand is a soft robotic hand developed by the Soft Robotics Lab at ETH Zürich, associated with ORCA Hand. It was created as a research platform for dexterous manipulation, with an emphasis on human-like hand behavior and compliance rather than a productized commercial system.
Publicly available information on OrcaHand is limited, and I do not have enough reliable detail to confirm its first release year or whether development on the model ended. The hand appears in the context of academic robotics research, where it has been used as a platform for studying manipulation tasks that benefit from soft, adaptive contact.
Specifications
Body
- Weight
- 1.2 kg
- Degrees of freedom
- 17
- DoF (hands)
- 17
- Fingers
- 5
- Structural material
- 3D-printed components with silicone skin for compliant contact
- Size
- Human-hand sized, anthropomorphic design
Motion
- Strength
- 5 kg
- Motor tech
- DYNAMIXEL servo motors with tendon-driven actuation
- Gear tech
- tendon-driven mechanism
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- robotics research
- Country
- Switzerland
- Availability
- Commercial
- Price
- $ 3 500