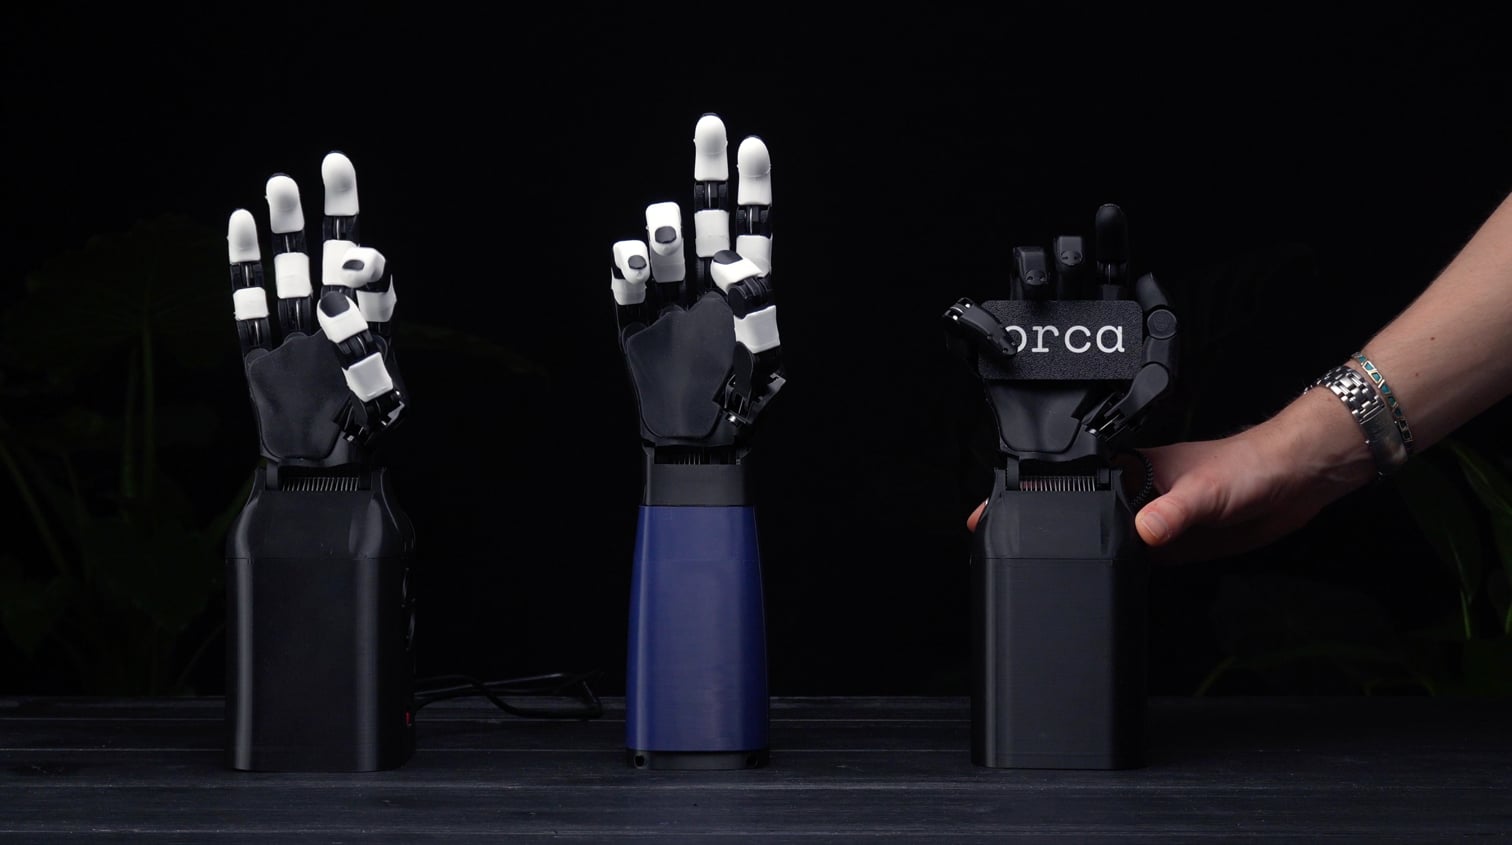
OrcaHand Lite
Commercial$1,500
Soft robotic hand for manipulation and integration in robotics research and applications. It weighs 0.7 kg and has 9 DoF.
- Weight
- 0.7 kg
- Degrees of freedom
- 9
- Strength
- 3 kg
About
OrcaHand Lite is a soft robotic hand developed by ORCA Hand and the Soft Robotics Lab at ETH Zürich for manipulation research and integration in robotic systems. It is described as a 0.7 kg hand with 9 degrees of freedom, placing it in the category of research-oriented end effectors rather than a mass-market product.
I do not have enough reliable source knowledge to establish a precise launch year, discontinuation year, or a detailed public timeline for this specific model. Based on what I know, it appears as part of ETH Zürich's broader work on soft robotic hands and dexterous manipulation, but I cannot confidently separate its public history from related ORCA Hand developments.
Specifications
Body
- Weight
- 0.7 kg
- Degrees of freedom
- 9
- Fingers
- 5
- Structural material
- 3D-printed components with silicone skin for compliant contact
- Size
- Human-hand sized, anthropomorphic design
- Shipping size
- Human-hand sized
Motion
- Strength
- 3 kg
- Motor tech
- Feetech HL-3915 + HL-3930
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- robotics research and applications
- Country
- Switzerland
- Availability
- Commercial
- Price
- $ 1 500