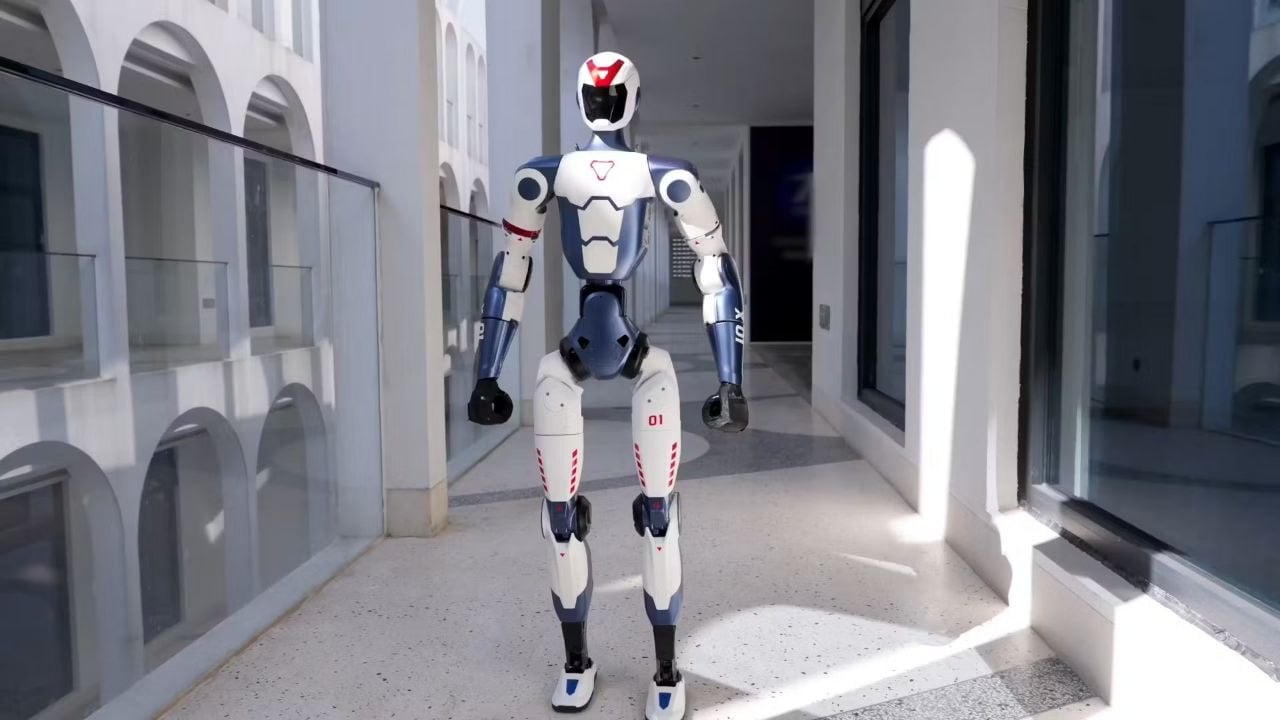
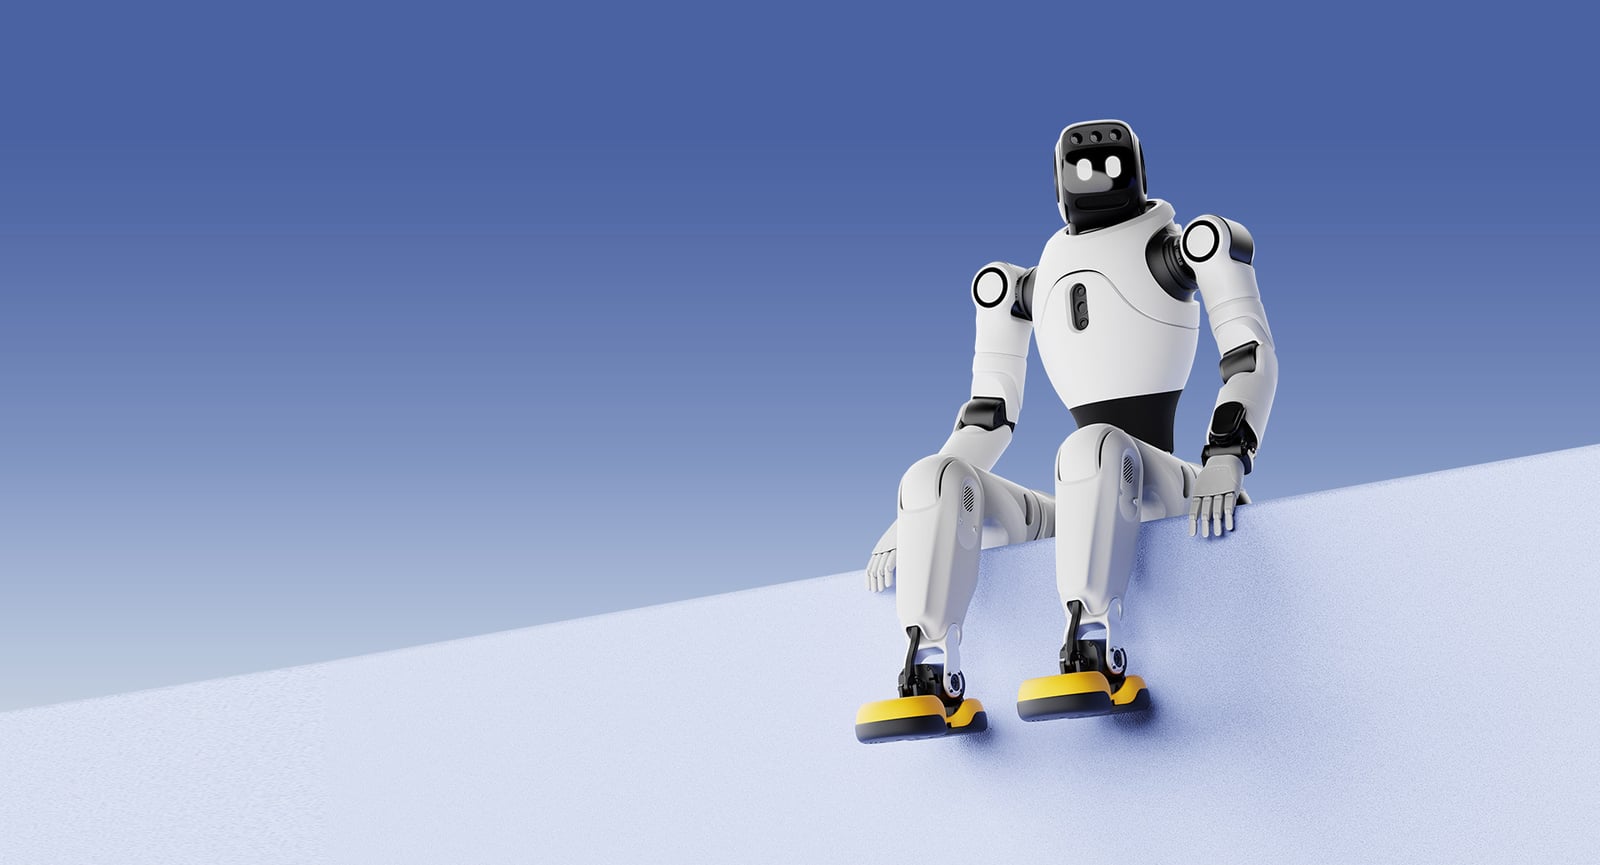
AgiBot X1 vs G1
AgiBot X1 is a humanoid robot by AGIBOT (China); G1 comes from Unitree Robotics (China). AgiBot X1 is taller at 133 cm, against 127 cm for G1. AgiBot X1 is heavier: 44 kg versus 35 kg for G1. AgiBot X1 has more degrees of freedom (34 against 23). Both are commercially available. Listed prices: $20,000 for AgiBot X1 and $16,000 for G1.
Add up to two more robots or show only the rows that differ.
| Spec | 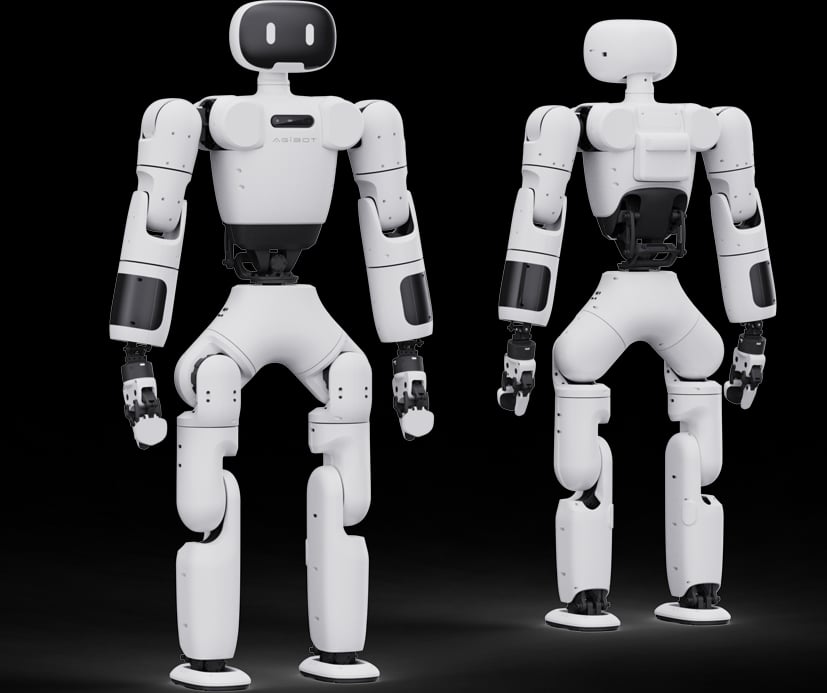  🇨🇳 ChinaCommercial | 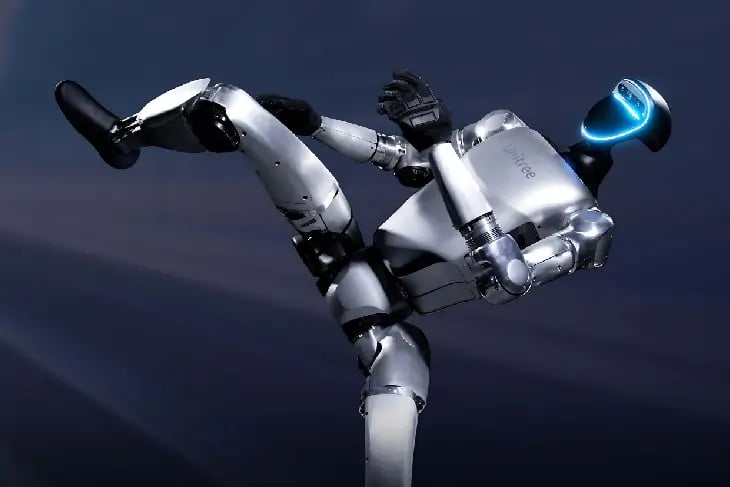  🇨🇳 ChinaCommercial |
|---|---|---|
| Overview | ||
| Year | ||
| Year | 2024 | 2024 |
| Body | ||
| Height | ||
| Height | 133 cm | 127 cm |
| Weight | ||
| Weight | 44 kg | 35 kg |
| Degrees of freedom | ||
| Degrees of freedom | 34 | 23 |
| DoF (hands) | ||
| DoF (hands) | - | 14 |
| Fingers | ||
| Fingers | 4 | 10 |
| Structural material | ||
| Structural material | Aluminium, composite shell over alloy frame | - |
| Size | ||
| Size | Φ86*80.7mm (PowerFlow R86-3); Φ86*58.1mm (PowerFlow R86-2); Φ52*71.6mm (PowerFlow R52) | G1 / G1 EDU |
| Shipping size | ||
| Shipping size | - | 1320 x 450 x 200 mm |
| Motion | ||
| Max speed | ||
| Max speed | 3.6 km/h | 7.2 km/h |
| Walking speed | ||
| Walking speed | 3.6 km/h | 4.5 km/h |
| Strength | ||
| Strength | 0.5 kg | 3 kg |
| Runtime | ||
| Runtime | 2 h | 2 h |
| Motor tech | ||
| Motor tech | PowerFlow quasi-direct-drive servo modules (R86/R52/L28 series) | Low inertia high-speed internal rotor PMSM (permanent magnet synchronous motor) |
| Gear tech | ||
| Gear tech | Integrated low-ratio (<10 : 1) planetary reducers inside servos | Industrial grade crossed roller bearings |
| Sensing & Compute | ||
| CPU / GPU | ||
| CPU / GPU | Open architecture – user supplies host PC/Jetson; onboard DCU real-time controllers (1 kHz, 100 Mbps) | 8-core high-performance CPU; EDU with Jetson Orin module as an additional option |
| Operating system | ||
| Operating system | Linux | Supports OTA updates and secondary development (EDU versions) |
| LLM integration | ||
| LLM integration | DIY: hooks for external LLMs via ROS2/AimRT; no bundled model | UnifoLM (Unified Robot Large Model) |
| Camera | ||
| Camera | Optional RGB-D camera | Intel RealSense D435i depth camera and Livox MID360 3D LiDAR; microphone array and stereo speaker in EDU versions |
| Connectivity | ||
| Connectivity | Ethernet, FDCAN/CAN-FD, GPIO, OTA firmware, UART | Wi-Fi 6 and Bluetooth 5.2 |
| Tactile / force sensors | ||
| Tactile / force sensors | - | force-position hybrid control |
| Safety & Market | ||
| Safe with humans | ||
| Safe with humans | Yes | Yes |
| Primary market | ||
| Primary market | Research & education labs, maker spaces, developer communities | civilian robot |
| Country | ||
| Country | China | China |
| Availability | ||
| Availability | Commercial | Commercial |
| Price | ||
| Price | $ 20 000 | $ 16 000 |
| Verified facts | ||
| All reviewed facts | ||
| All reviewed facts | - | 4 |
Counts of reviewed facts with sources. Open a robot page to see each fact and its links.