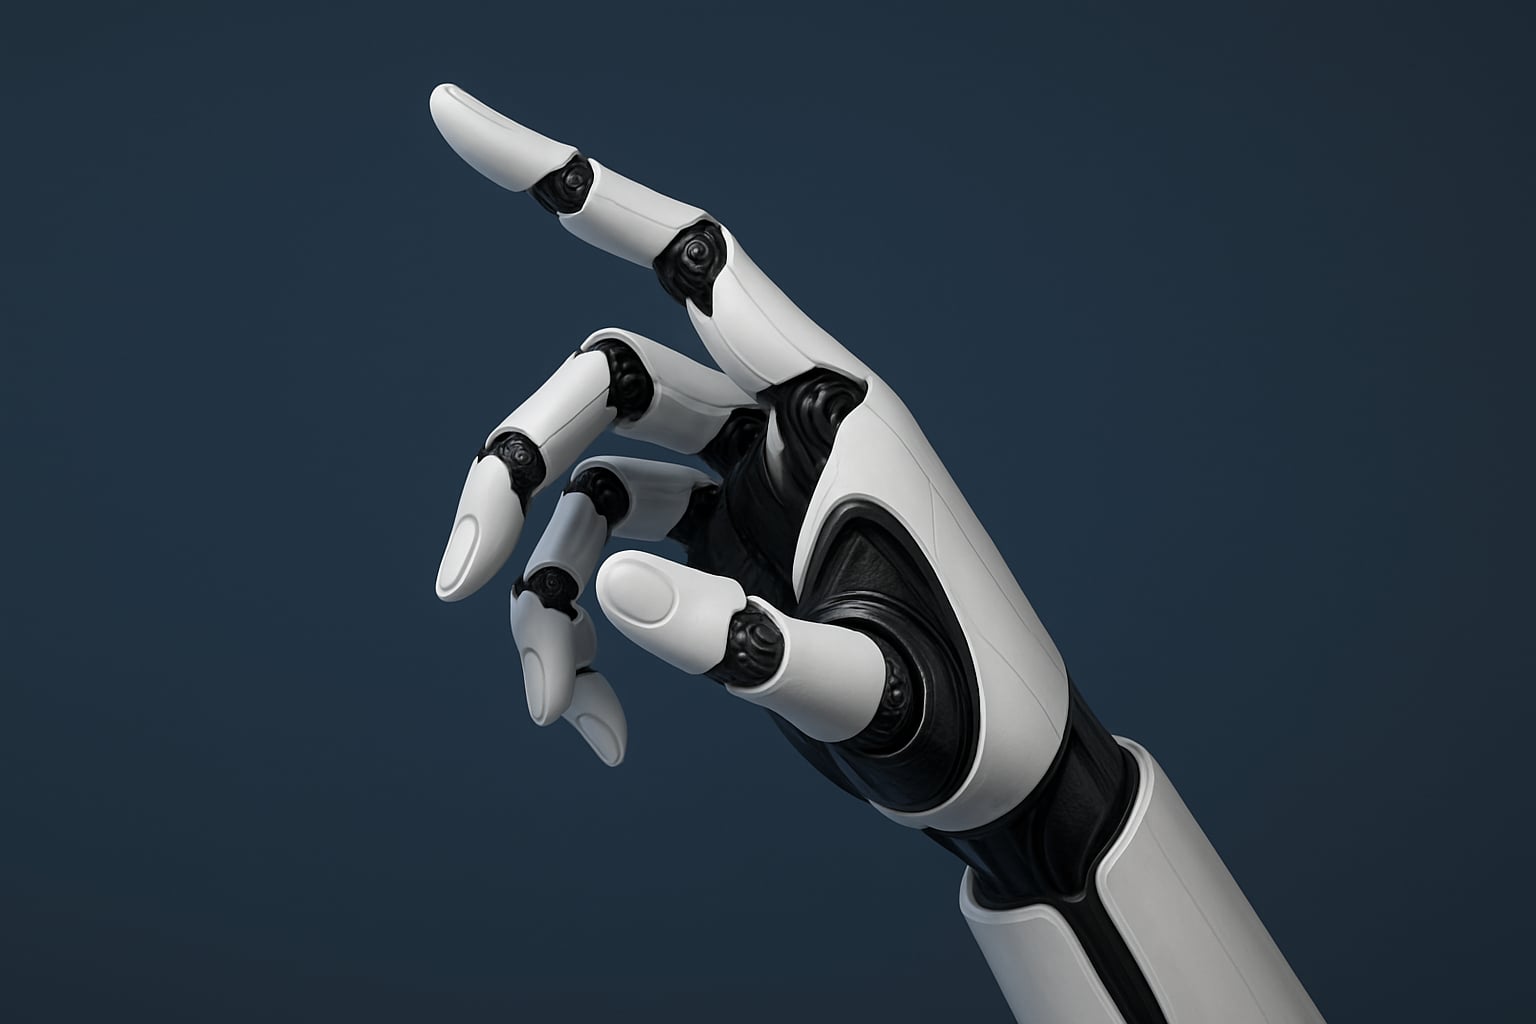
Lightweight, five-finger tendon-driven robotic hand with 7 active DOF for embodied-AI research. It is listed for manipulation, reinforcement learning, and sim-to-real studies.