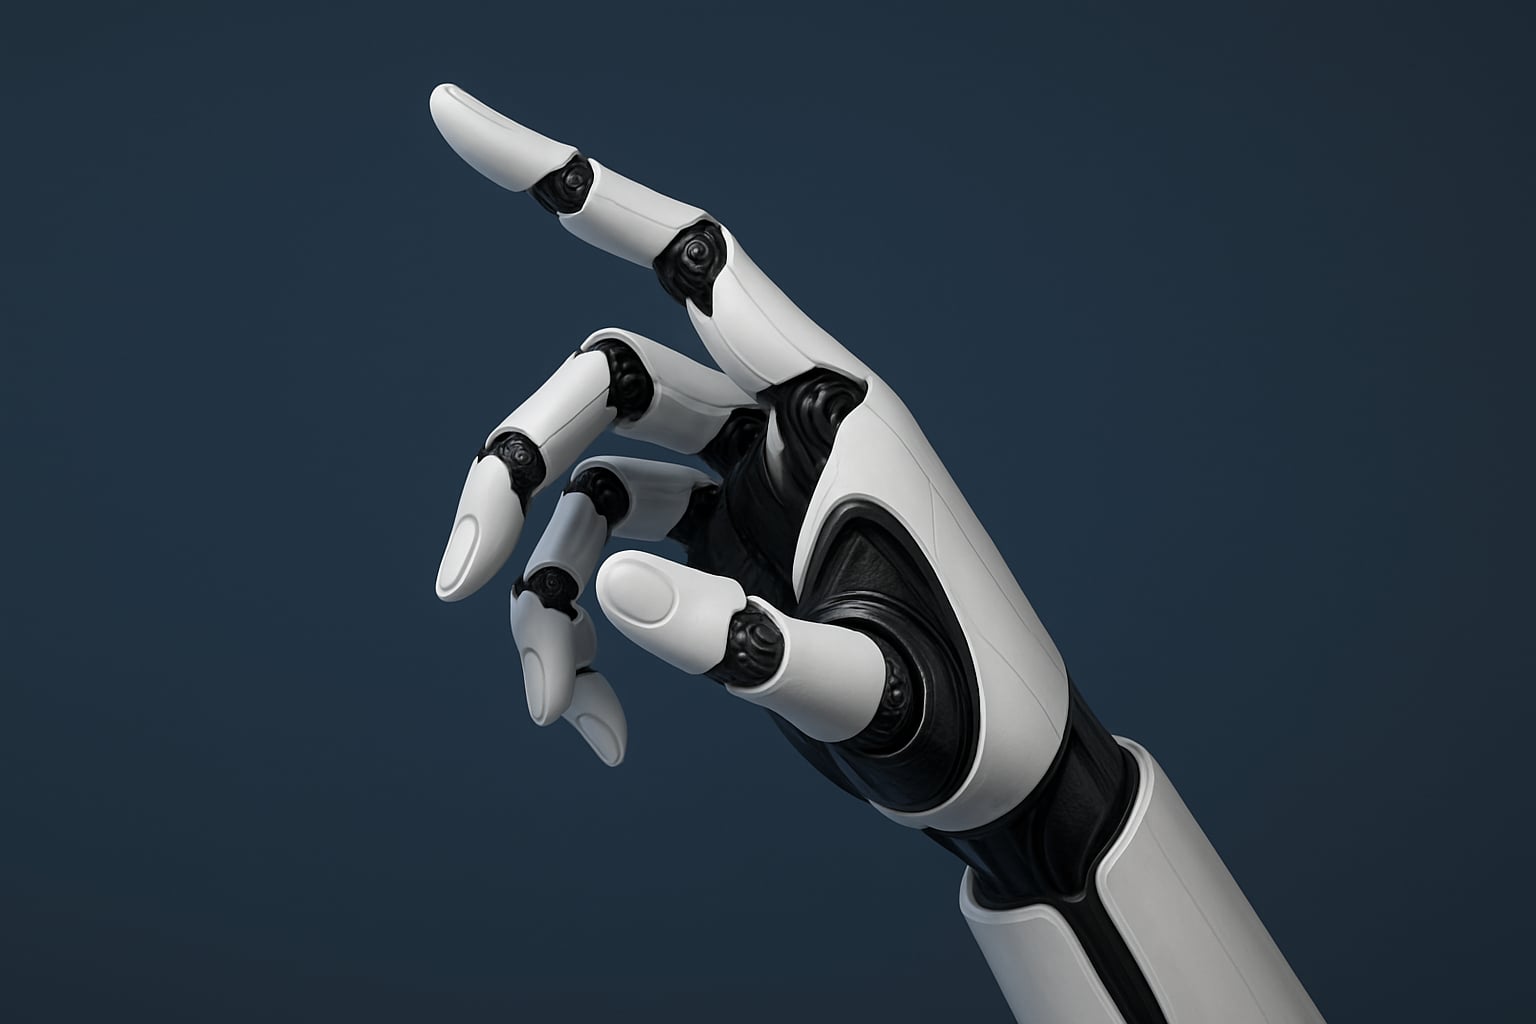
Aero Hand Open
Commercial$720
Lightweight, five-finger tendon-driven robotic hand with 7 active DOF for embodied-AI research. It is listed for manipulation, reinforcement learning, and sim-to-real studies.
- Weight
- 0.4 kg
- Degrees of freedom
- 7
- Strength
- 30 kg
About
I don’t have reliable historical information about a robot model called Aero Hand Open from TetherIA in my training data. I can’t confirm a founding year, release history, or discontinuation date for this specific model.
Based on the description provided, it appears to be a lightweight five-finger tendon-driven robotic hand intended for embodied-AI and manipulation research, but I do not have enough verified detail to reconstruct a factual timeline.
Specifications
Body
- Weight
- 0.4 kg
- Degrees of freedom
- 7
- DoF (hands)
- 16
- Fingers
- 5
- Structural material
- Nylon
- Shipping size
- 50 × 50 × 50 cm
Motion
- Strength
- 30 kg
- Motor tech
- 7 coreless serial-bus servos; cable/tendon-driven; back-drivable
Sensing & Compute
- CPU / GPU
- ESP32-S3 controller
- Connectivity
- USB 2.0
- Tactile / force sensors
- No
Safety & Market
- Primary market
- Embodied-AI research / manipulation / reinforcement learning / sim-to-real studies
- Country
- US
- Availability
- Commercial
- Price
- $ 720