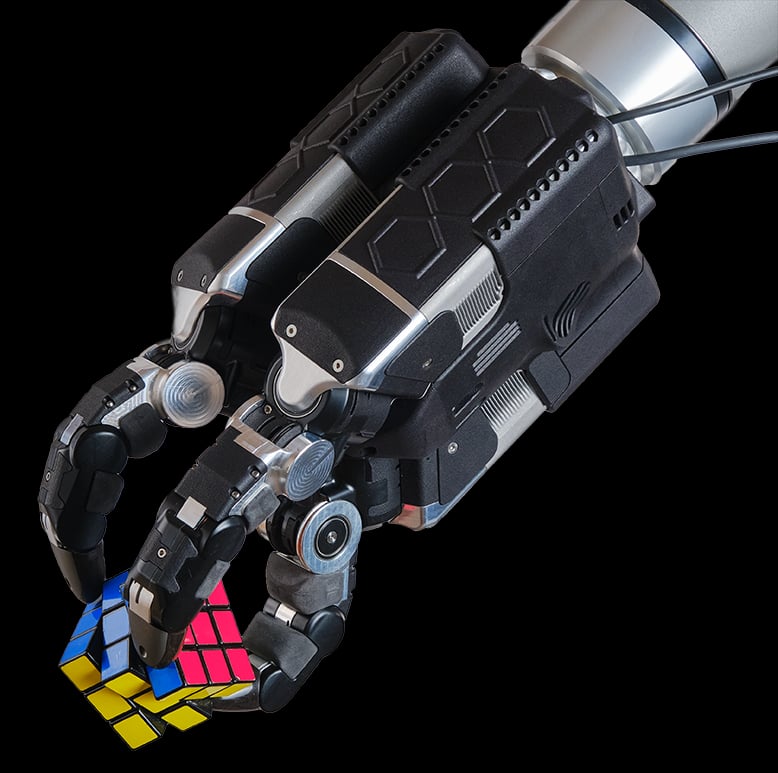
DEX-EE
Commercial$60,000
A dexterous robotic hand for academic and applied research, machine learning, and dexterous manipulation research. It has modular fingers, robust construction, rich tactile sensing, 12 DoF, and 12 hand DoF.
- Height
- 35 cm
- Weight
- 0.9 kg
- Degrees of freedom
- 12
- Strength
- 5 kg
About
DEX-EE is a dexterous robotic hand developed by Shadow Robot Company in the UK for research use. It was created for academic and applied work in manipulation, machine learning, and tactile interaction, with a design that emphasizes modularity and sensor-rich operation.
The hand builds on Shadow Robot Company’s earlier dexterous hand platforms and is aimed at laboratories that need a robust hand with rich tactile feedback and multiple degrees of freedom. I do not have enough reliable information to confirm a specific launch year or discontinuation date for this model.
Specifications
Body
- Height
- 35 cm
- Weight
- 0.9 kg
- Degrees of freedom
- 12
- DoF (hands)
- 12
- Fingers
- 3
- Size
- 350mm height
- Shipping size
- 50 × 50 × 50 cm
Motion
- Strength
- 5 kg
- Motor tech
- Tendon-driven, 20 motors; EtherCAT
Sensing & Compute
- Connectivity
- EtherCAT
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- Academic and applied research; machine learning; dexterous manipulation research
- Country
- UK
- Availability
- Commercial
- Price
- $ 60 000