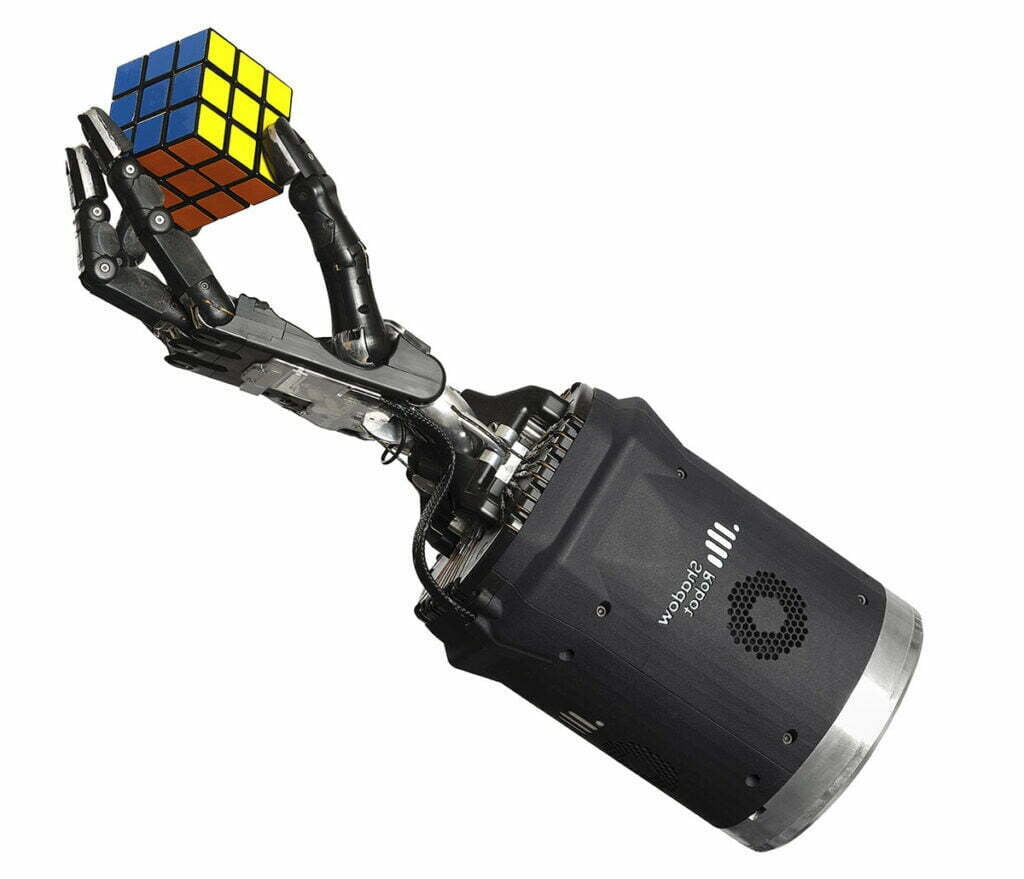
Dexterous Hand
CommercialActive since 2001$65,000
A humanoid robotic hand with 20 actuated DoF, rich tactile sensing, and 24 total joint movements for manipulation and research. It is used in academic labs, industrial automation projects, and teleoperation systems.
- Weight
- 4.3 kg
- Degrees of freedom
- 20
- Strength
- 5 kg
About
Shadow Robot Company’s Dexterous Hand emerged from the company’s work on anthropomorphic manipulation and teleoperation in the early 2000s. It was developed as a robotic hand platform for research and integration, with the goal of giving laboratories and industrial partners a hand-sized system that could be used for grasping, dexterous manipulation, and control studies.
Over time, the Dexterous Hand became one of Shadow Robot Company’s core products and a common reference platform in robotics research. It has been iterated to include higher levels of actuation, tactile sensing, and compatibility with teleoperation and manipulation experiments. The hand has been used in academic and industrial settings where researchers need a detailed, instrumented hand model rather than a simple gripper.
Specifications
Body
- Weight
- 4.3 kg
- Degrees of freedom
- 20
- DoF (hands)
- 20
- Fingers
- 5
- Structural material
- Composite of aluminium, brass, plastics and engineered polymers for strength and precision
- Size
- Similar to a human hand plus integrated forearm; exact published dimensions vary.
- Shipping size
- ~400–500 mm total assembly length (hand + integrated forearm)
Motion
- Strength
- 5 kg
- Motor tech
- Electric “Smart Motor” tendon-driven system with integrated force & position control
Sensing & Compute
- Connectivity
- ROS and EtherCAT-based systems
- Tactile / force sensors
- Yes; over 100 sensor channels
Safety & Market
- Primary market
- academic labs, industrial automation projects, and teleoperation systems
- Country
- UK
- Availability
- Commercial
- Price
- $ 65 000
Timeline4
- 2018-01-01 · milestone~Platform integrates into teleoperation systems
The hand continues to be used as a controlled end-effector in teleoperated manipulation setups.
- 2012-01-01 · milestone~Dexterous Hand sees wider research use
The hand is adopted in academic labs and applied robotics projects for dexterous grasping studies.
- 2006-01-01 · milestone~Hand supports richer tactile sensing
The platform evolves with additional sensing and control features for laboratory manipulation work.
- 2001-01-01 · milestone~Shadow Robot introduces Dexterous Hand
Shadow Robot Company begins offering its dexterous robotic hand platform for manipulation and teleoperation research.