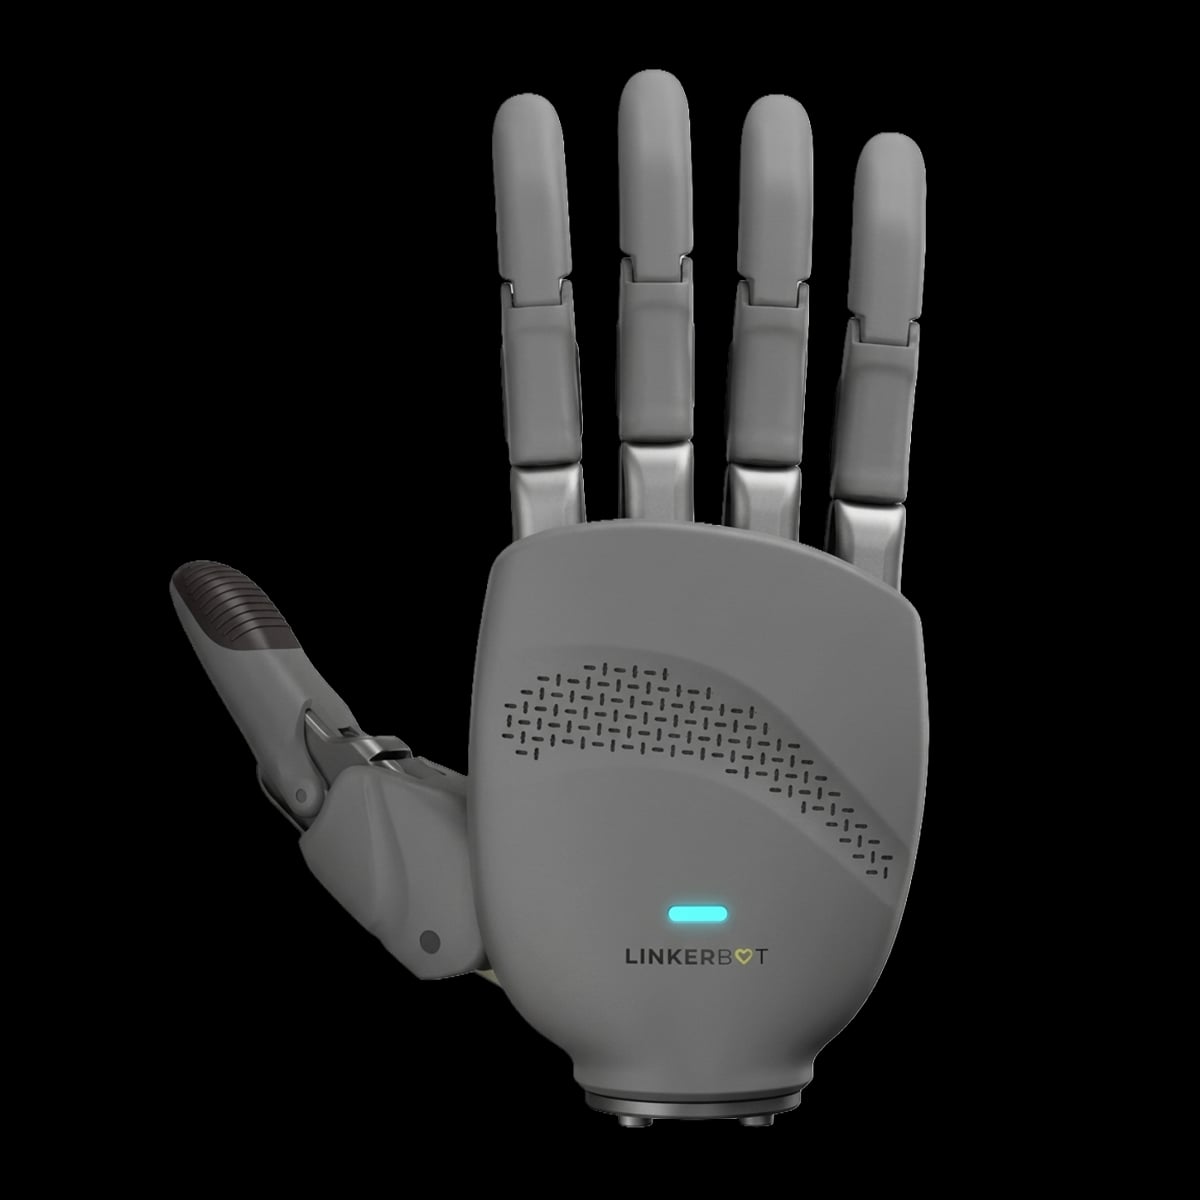
Linker O6
Commercial$1,800
Lightweight five-finger robotic hand for precise, adaptive grasping in robotics, automation, and research applications.
- Weight
- 0.4 kg
- Strength
- 50 kg
About
I don’t have reliable historical information about the LINKERBOT Linker O6 in my training data. I can identify it as a lightweight five-finger robotic hand intended for adaptive grasping in robotics, automation, and research, but I can’t confidently place its launch, deployment, or discontinuation dates.
Because I can’t verify specific milestones, I’m leaving the timeline empty rather than guessing. If you have a product sheet, announcement, or archived release note, I can help turn that into a structured history.
Specifications
Body
- Weight
- 0.4 kg
- DoF (hands)
- 6
- Fingers
- 5
- Structural material
- Aluminum alloy + engineering polymers
- Size
- 177 × 76.5 × 40 mm
- Shipping size
- 177 × 76.5 × 40 mm
Motion
- Strength
- 50 kg
- Motor tech
- High-torque servo modules with worm gear transmission
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- robotics, automation, and research applications
- Country
- China
- Availability
- Commercial
- Price
- $ 1 800