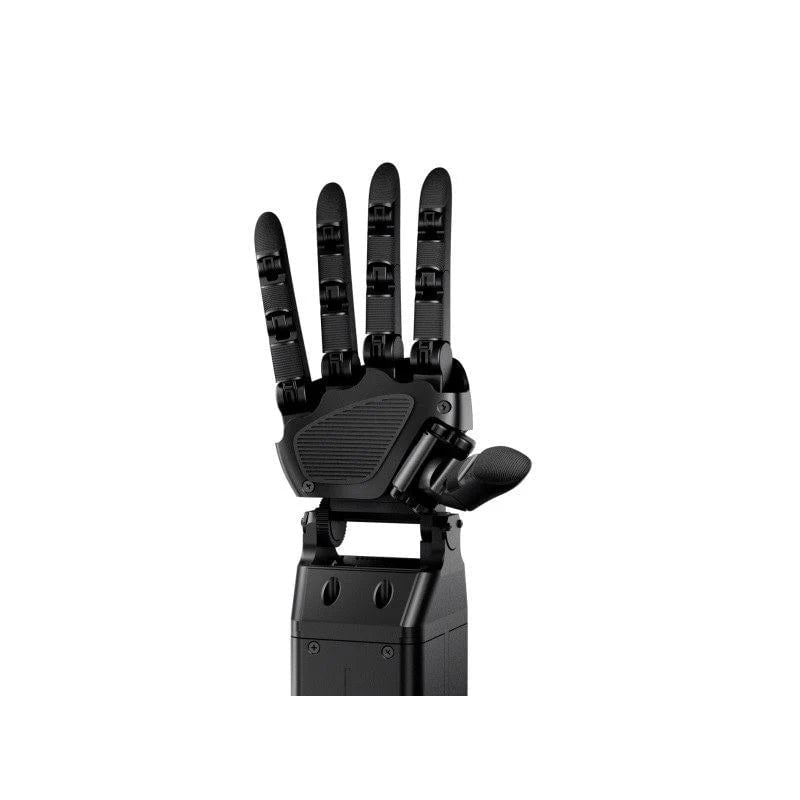
Linker L30
Commercial$14,500
A tendon-driven robotic hand with 25 hand DoF and a 1.3 kg weight. It is used in advanced robotics, industrial automation, and humanoid applications.
- Weight
- 1.3 kg
- Strength
- 8 kg
About
I don’t have enough reliable information in my training data to identify a documented history for the LINKERBOT Linker L30. I can confirm from the description that it is a tendon-driven robotic hand with 25 hand degrees of freedom and a reported weight of 1.3 kg, intended for advanced robotics, industrial automation, and humanoid applications.
Because I cannot verify a public launch date, release timeline, or discontinuation status from the knowledge available to me, I am leaving the founding and end years unset and providing no timeline events rather than risk inventing details.
Specifications
Body
- Weight
- 1.3 kg
- DoF (hands)
- 25
- Fingers
- 5
- Structural material
- Aluminum alloy + high-performance engineering polymers
- Size
- 230 x 90 x 50 mm
- Shipping size
- 230 x 90 x 50 mm
Motion
- Strength
- 8 kg
- Motor tech
- Tendon-driven (bionic cable actuation system)
Sensing & Compute
- Connectivity
- Integrates with standard robotic systems; supports flexible control setups
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- advanced robotics, industrial automation, and humanoid applications
- Country
- China
- Availability
- Commercial
- Price
- $ 14 500