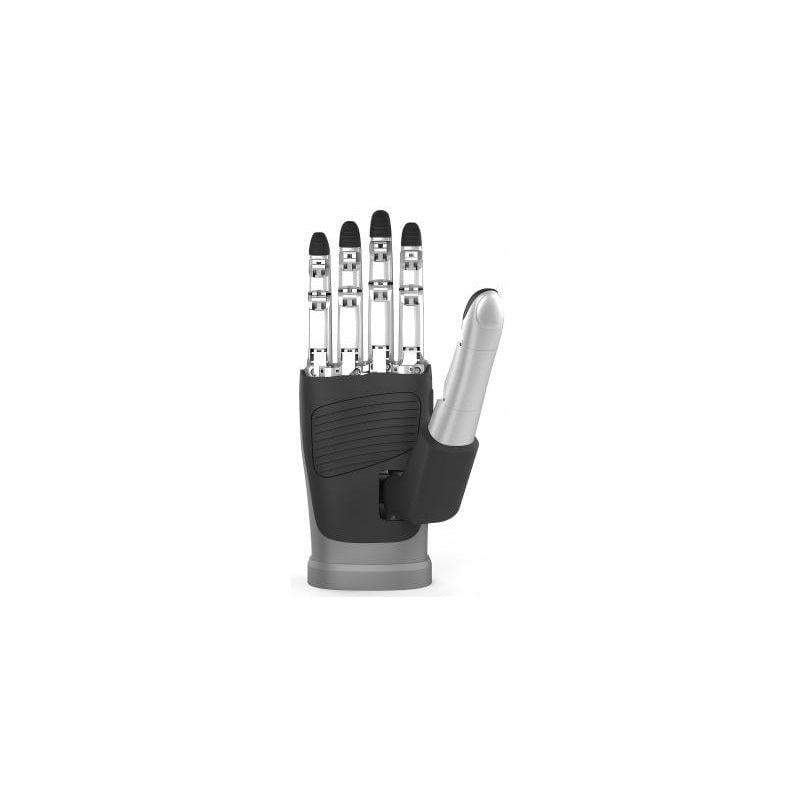
A compact humanoid robotic hand for precise grasping and natural movement, with 16 hand DoF and a 0.76 kg weight. It targets research, robotics integration, and light industrial tasks.