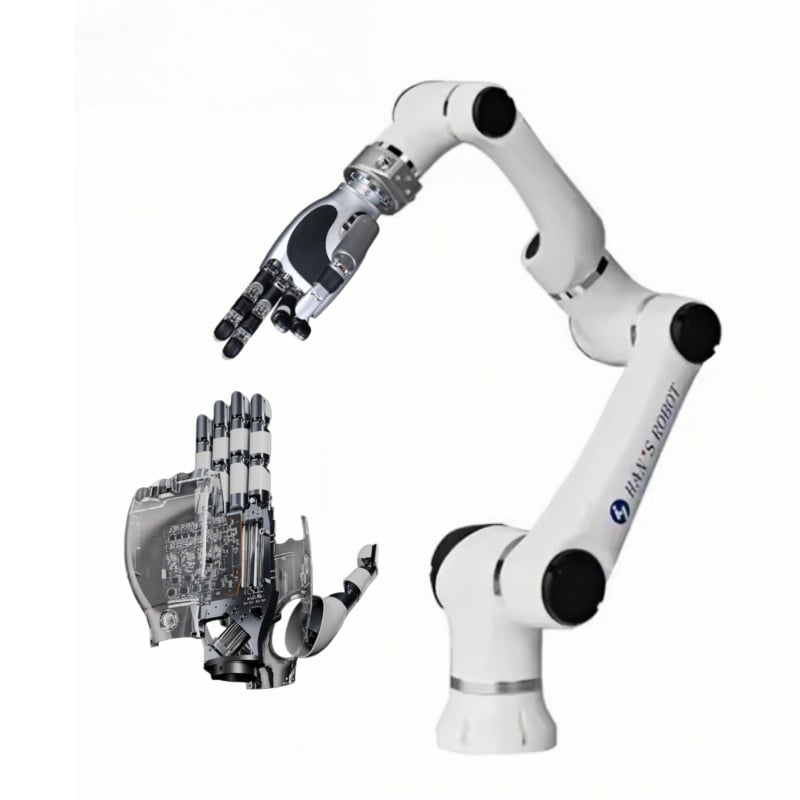
Integrated robotic hand with human-style gripping motion for research, humanoid robotics, and advanced automation.