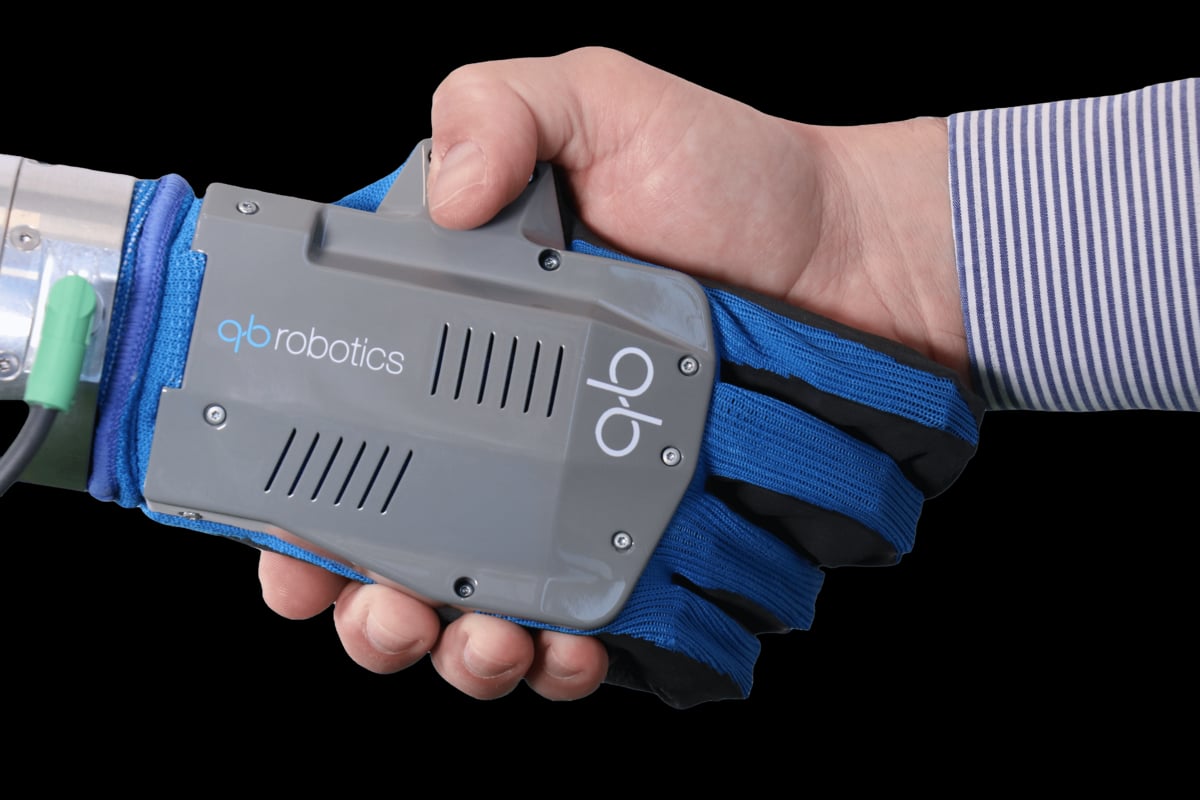
An adaptive robotic hand with soft, flexible fingers for stable, human-like grasping in research, lab, and collaborative settings.