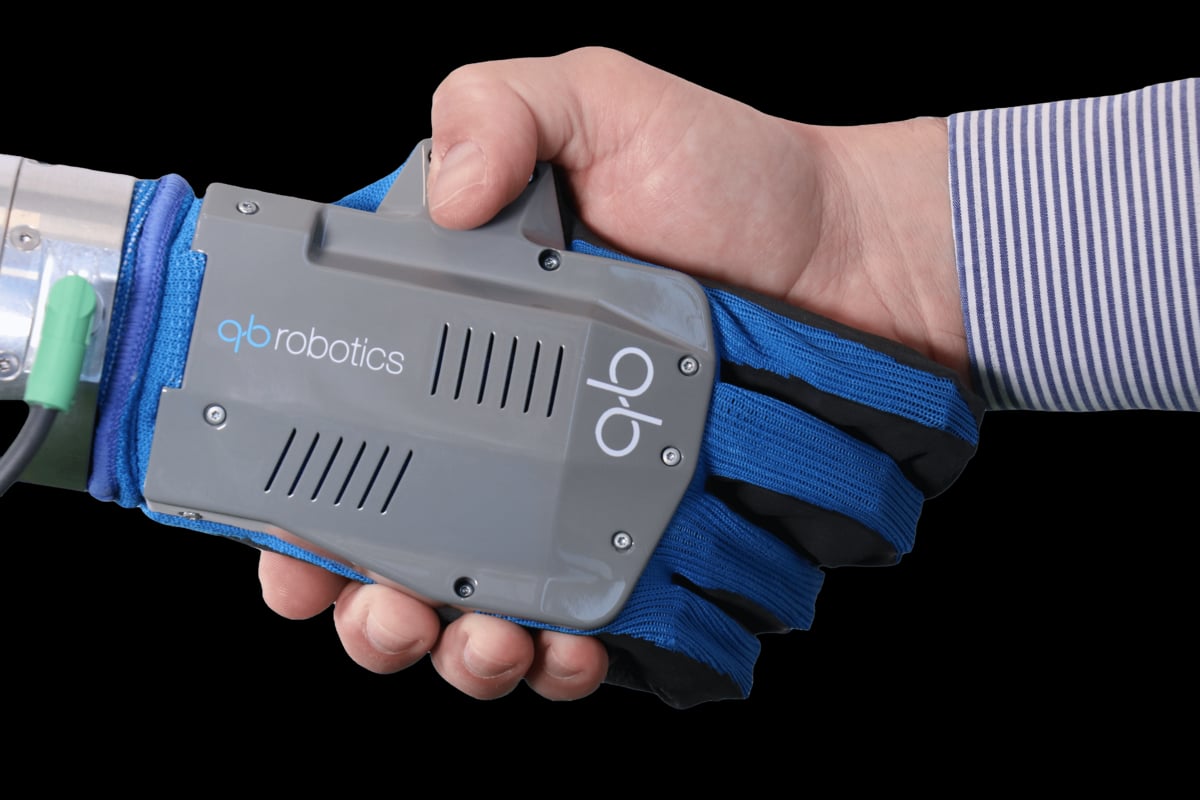
SoftHand2
CommercialActive since 2016$16,500
An adaptive robotic hand with soft, flexible fingers for stable, human-like grasping in research, lab, and collaborative settings.
- Weight
- 0.9 kg
- Degrees of freedom
- 19
- Strength
- 3 kg
About
qb Robotics’ SoftHand2 is part of the SoftHand family of underactuated robotic hands developed around the Italian Institute of Technology’s soft robotics work. It was introduced as a research-oriented hand designed to combine compliance, adaptability, and simple mechanical structure for grasping a wide range of objects.
SoftHand2 followed earlier SoftHand designs by refining the hand for practical use in lab and collaborative contexts. Its soft fingers and tendon-driven architecture support stable grasps without requiring complex finger-by-finger control, making it a common platform for research on manipulation, prosthetics, and human-robot interaction.
Specifications
Body
- Weight
- 0.9 kg
- Degrees of freedom
- 19
- DoF (hands)
- 19
- Fingers
- 5
- Structural material
- Soft, compliant materials for fingers with internal tendon/cable mechanism; skeletal links and palm structure use standard robotics materials (metal/plastic)
- Size
- human-hand sized
- Shipping size
- human-hand sized
Motion
- Strength
- 3 kg
- Motor tech
- Electric DC motors driving tendon (or cable)-based soft robotics actuation; synergy-based under-actuated soft-hand design
Sensing & Compute
- Connectivity
- Engineers connect it to a robot and control it via standard communication protocols.
- Tactile / force sensors
- No
Safety & Market
- Safe with humans
- The design reduces risk when handling unpredictable or delicate items and is described as a good choice for mixed or collaborative environments.
- Primary market
- research, lab settings, delicate handling, mixed or collaborative environments
- Country
- Italy
- Availability
- Commercial
- Price
- $ 16 500
Timeline3
- 2018-01-01 · milestone~Laboratory deployments broaden
SoftHand2 appears in lab setups focused on teleoperation, grasp planning, and human-robot interaction.
- 2017-01-01 · milestone~Underactuated grasping research expands
Researchers use the hand in studies of compliant grasping and object manipulation across varied shapes and sizes.
- 2016-01-01 · release~SoftHand2 enters research use
qb Robotics introduces SoftHand2 as a soft, adaptive robotic hand for research and collaborative applications.