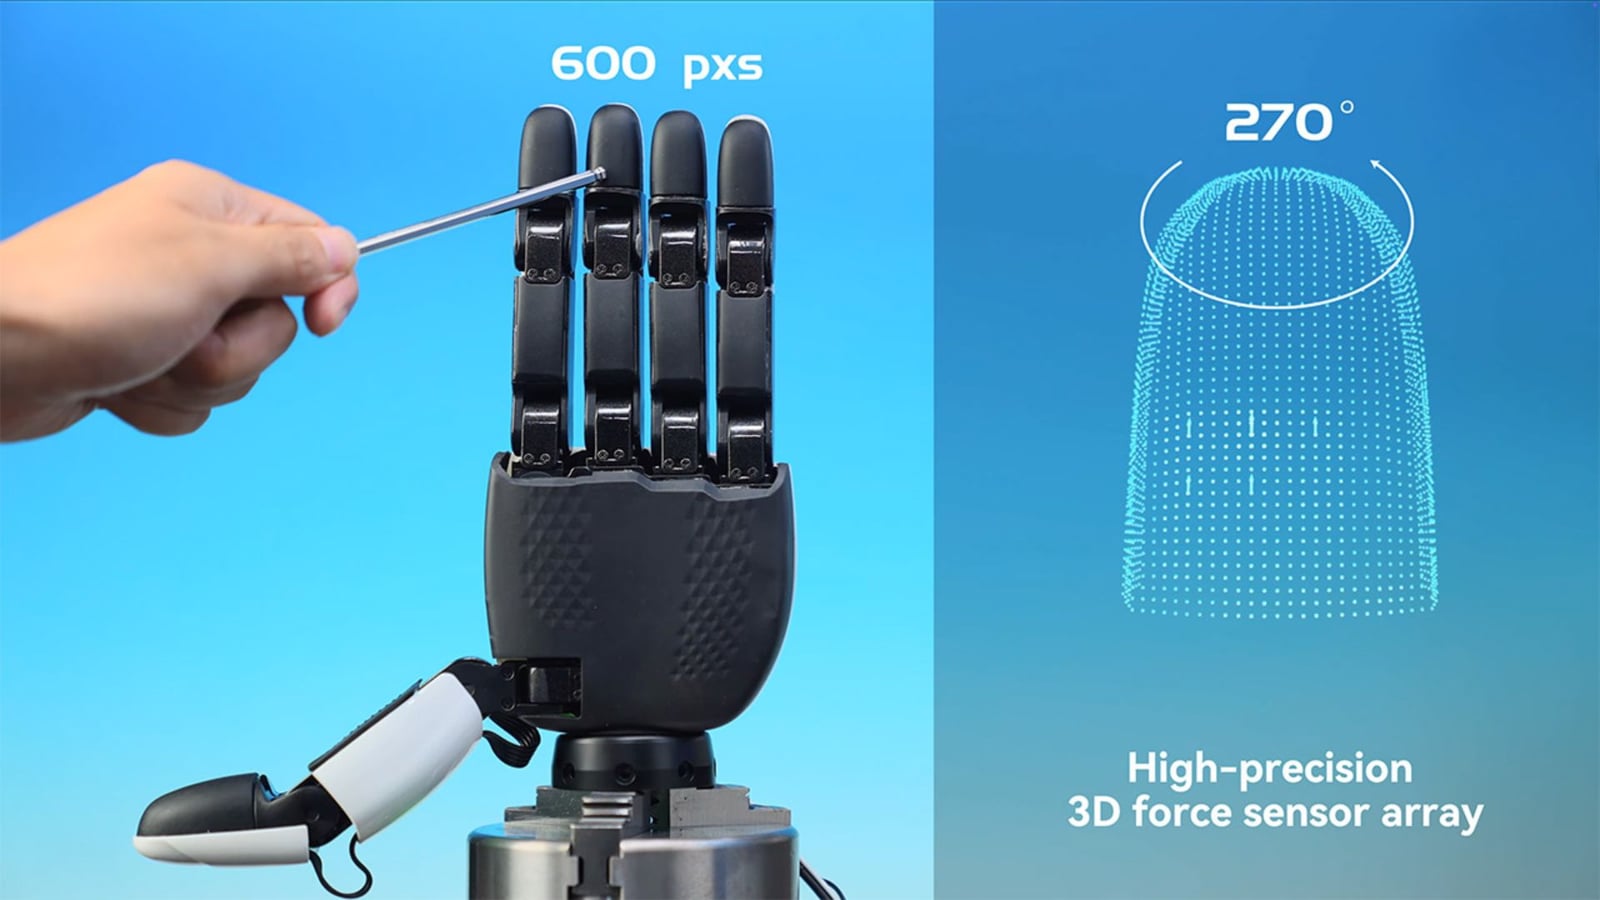
A 0.31 kg tendon-driven robotic hand with 6 hand DoF for research, education, and experimental robotics applications.