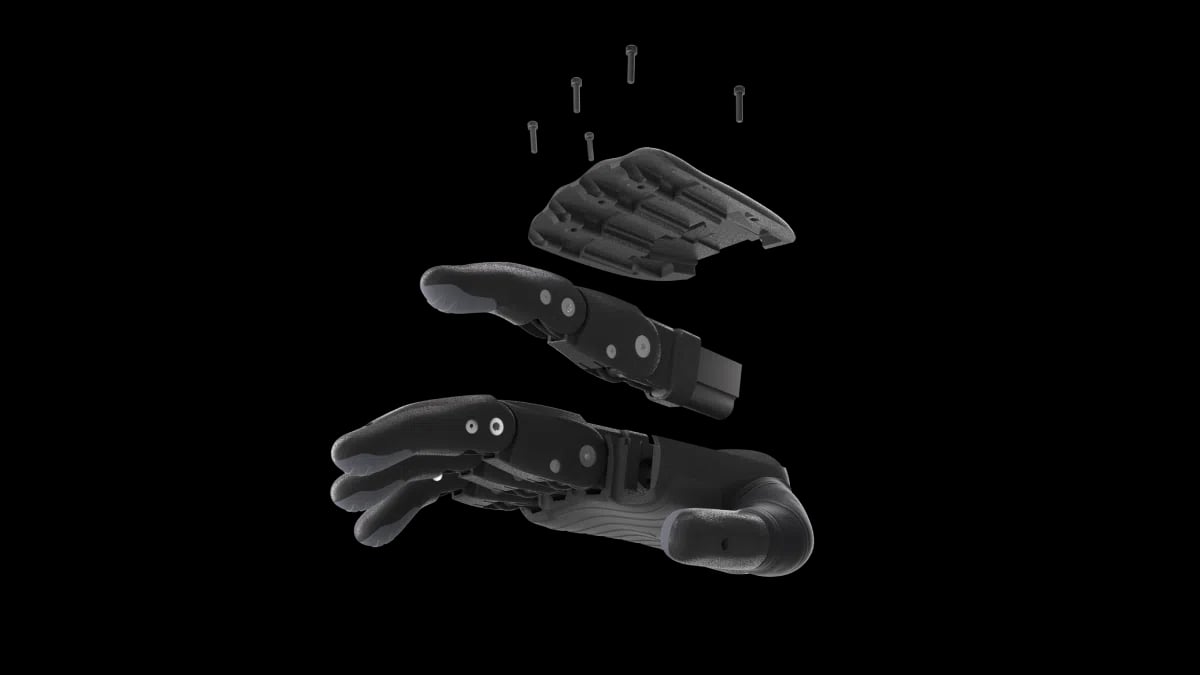
A humanoid robotic hand for research and teleoperation, with 6 hand DoF, 20 kg grip strength, and direct drive actuation. It is discontinued.