RealMan Robotics· Aug 24, 2026
How Physical AI Moves from Labs to the Real World | Bloomberg Interview
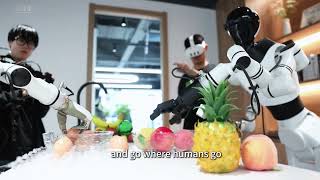
Kenneth Wren, director of overseas solutions at RealMan Robotics, discusses robot training and human-robot collaboration in a Bloomberg interview.
Edward Liu of RealMan Robotics explains how RealMan is building hardware, fleet operations, and data infrastructure to move physical AI from demos to daily work at the Humanoids Summit.
Liu contrasts a robot completing a task once with performing it reliably across four shifts, despite changes in objects or lighting. A deployed system must handle failures, recover, and produce results customers accept. With larger fleets, teams also need shared records of robot status, software, tasks, and responsible operators.
Liu describes four connected needs: physical execution, fleet operations, human support for difficult cases, and learning from real work. RealMan’s Global Labor Network connects remote operators to robots, allowing useful work to begin before full autonomy. As robots improve, people can shift from direct control to exception handling and supervising multiple robots.
RealMan’s three layers are deployable hardware and manufacturing, robot operations, and real-world data and learning. Liu says its joint modules have passed up to 50,000 hours MTBF, and the company has capacity for 10,000 complete robot systems and up to one million joint modules annually. He presents the 7.2-kilogram RM65 arm, with its controller integrated, as an example of reducing the weight and integration burden of a complete robot.
The operations platform links each robot’s task, operator, software configuration, and outcome, while distinguishing device health from whether a task is blocked. Liu says raw robot records become useful training data only when camera images, joint states, actions, and outcomes are synchronized and quality checked. Failures and human interventions can guide diagnosis, targeted training, evaluation, and monitored releases.
Liu describes deployments, pilots, supervised operation, and teleoperation across different markets, without claiming every application is fully autonomous. He proposes starting with one useful task and clear acceptance criteria, with customers, integrators, and model teams contributing alongside RealMan. Examples include factory machine tending and material handling, warehouse picking and sorting, and facility inspection.
Briefs summarise talks and interviews; timestamps open the video at that moment. Claims in a talk are the speaker's own.
Kenneth Wren, director of overseas solutions at RealMan Robotics, discusses robot training and human-robot collaboration in a Bloomberg interview.
Donny Li of RealMan discusses how robot hardware and real-world training data can accelerate everyday robot use at the Humanoids Summit.
Jenk Infang, head of RealMan Robotics’ humanoid robot data training center, introduces its Beijing facility and explains how it collects data to train humanoid robots for household and workplace tasks.