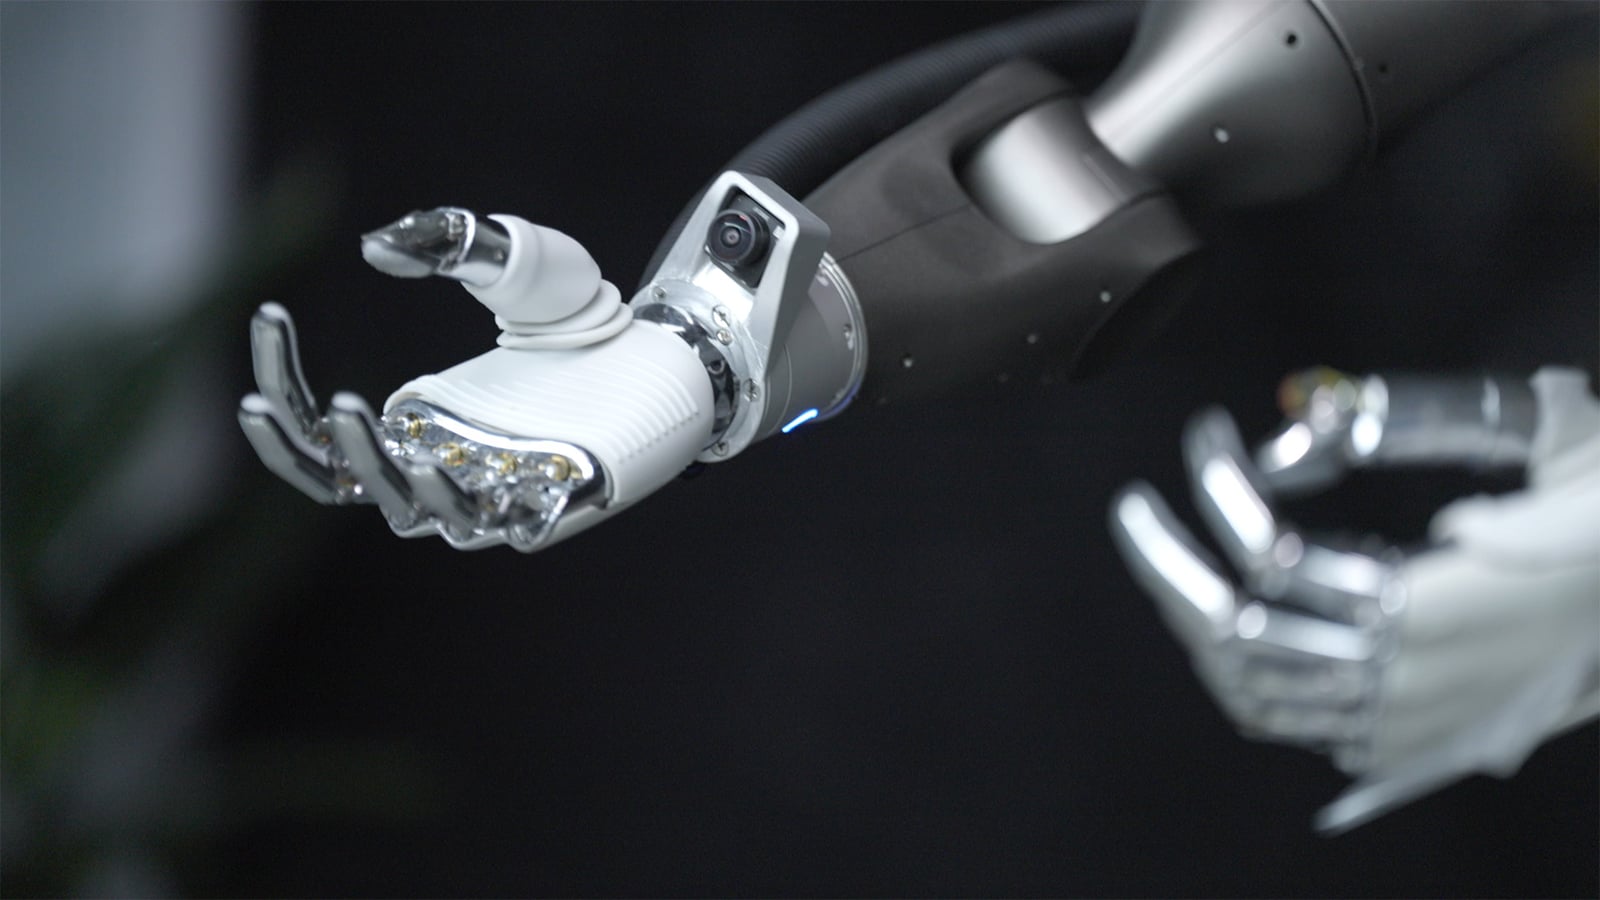
Psi H1
$9,500
Dexterous humanoid robotic hand for precise, adaptive manipulation in precision assembly and industrial handling. It has advanced tactile sensing, human-like motion control, 16 DoF, and 16 hand DoF.
- Weight
- 0.6 kg
- Degrees of freedom
- 16
- Strength
- 20 kg
About
Psi H1 appears to be a dexterous robotic hand attributed to PsiBot and described as a 16-DoF humanoid hand for precision assembly and industrial handling. I do not have reliable, model-specific historical information for its debut, development, or discontinuation.
Based on the available description alone, it is positioned as an adaptive manipulation component with tactile sensing and human-like motion control. I cannot verify the timeline beyond that basic functional description, so the model’s start and end years remain unknown.
Specifications
Body
- Weight
- 0.6 kg
- Degrees of freedom
- 16
- DoF (hands)
- 16
- Fingers
- 5
- Structural material
- Aluminum alloy + reinforced engineering polymers
Motion
- Strength
- 20 kg
- Motor tech
- Precision electric servo actuators with multi-mode control (position, speed, voltage)
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- precision assembly, industrial handling
- Country
- China
- Availability
- Status unknown
- Price
- $ 9 500