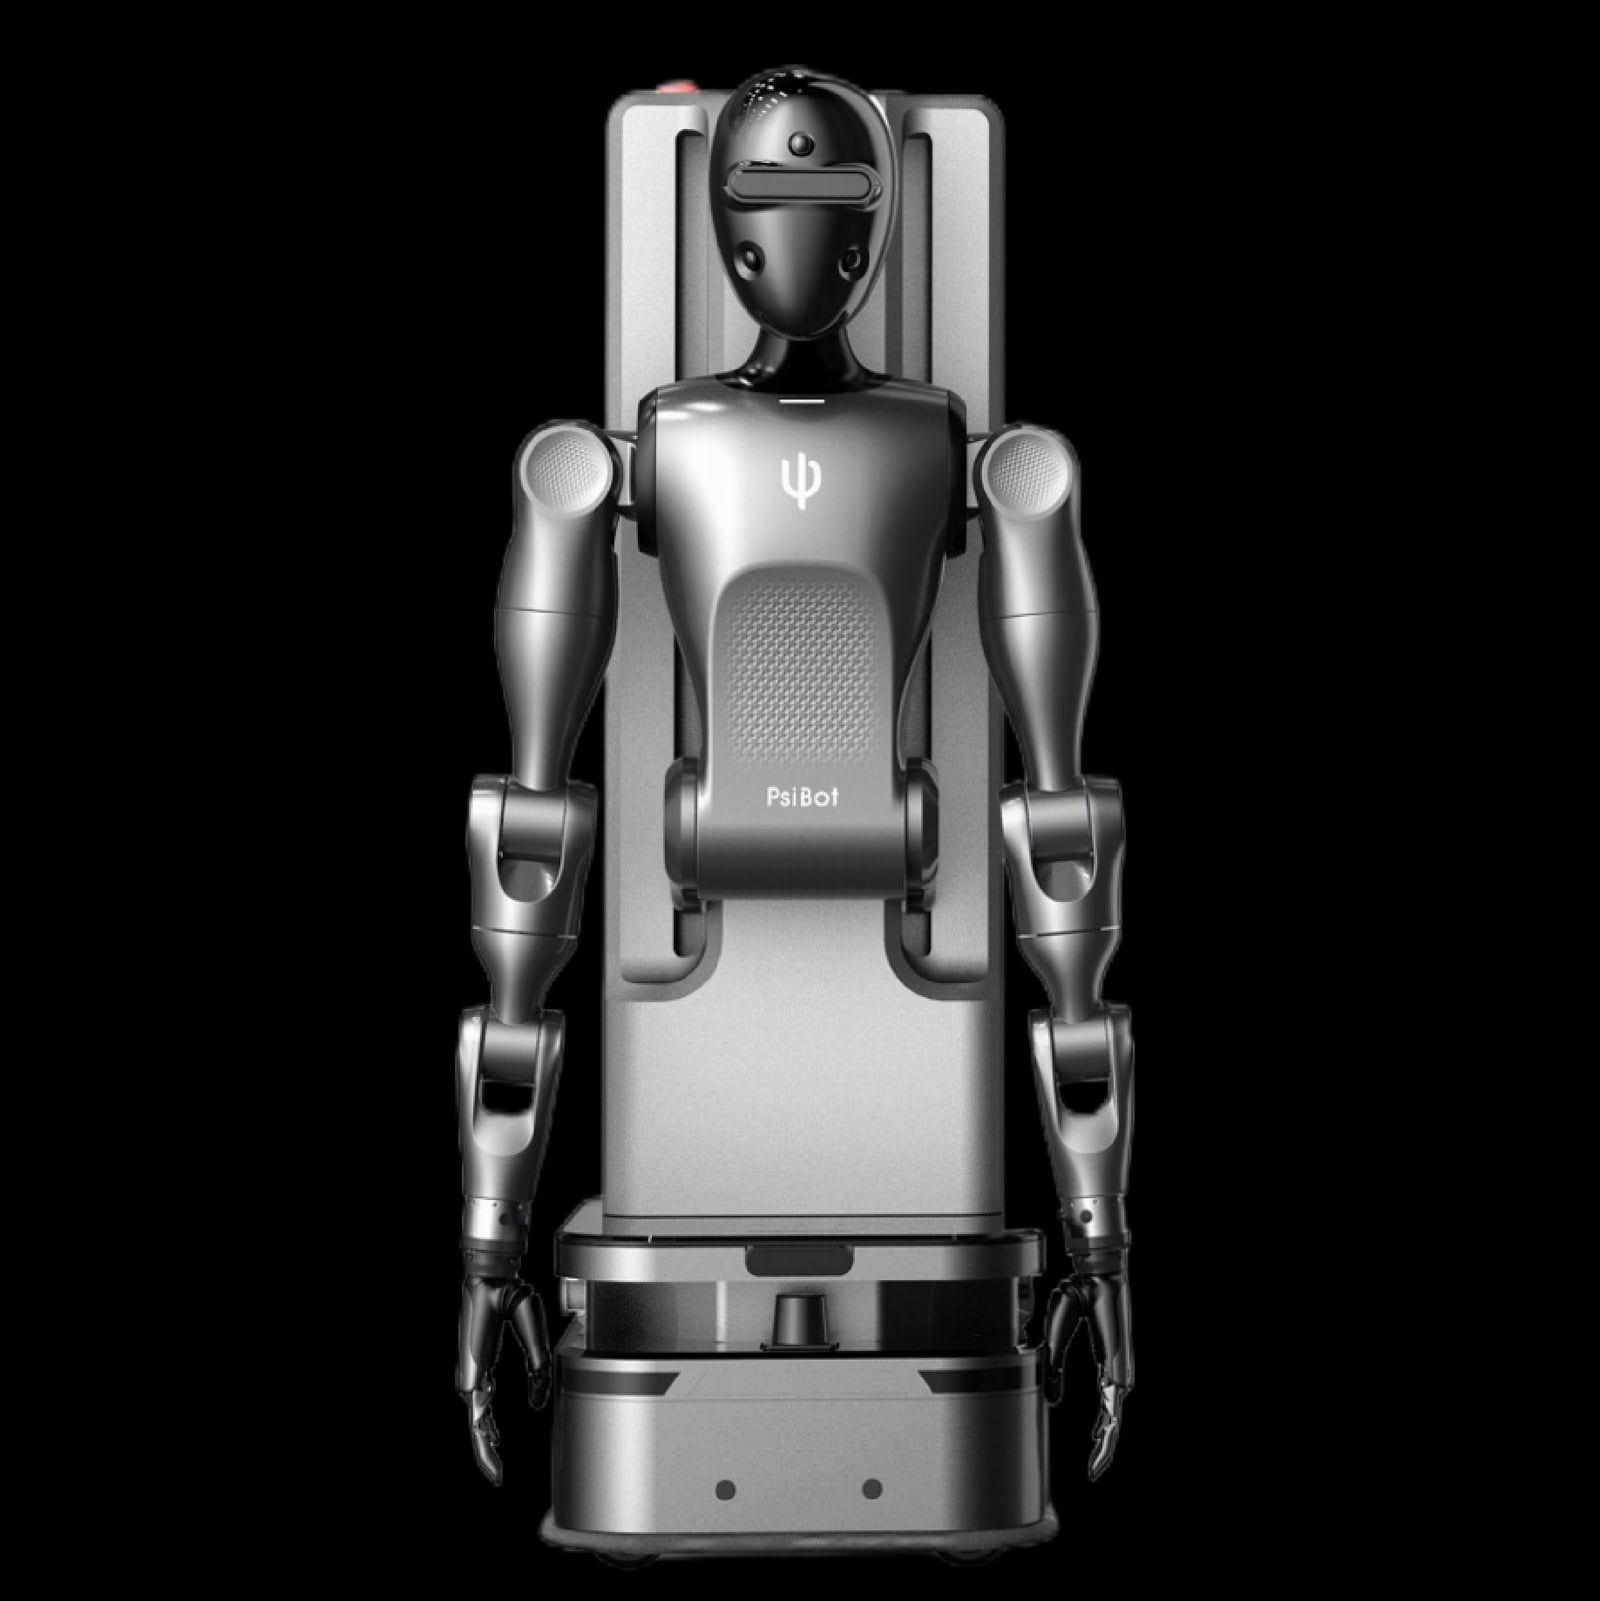
Psi E1
$0
An anthropomorphic exoskeleton for embodied AI data collection with real-time 1:1 human motion mapping. It works with VLA and embodied models.
About
Psi E1 is described as an anthropomorphic exoskeleton from PsiBot for embodied AI data collection. In that role, it maps human motion in real time at a 1:1 ratio, allowing operator movements to be captured for use with vision-language-action and other embodied models.
I do not have enough reliable historical information to confirm when Psi E1 was first introduced, when it began deployment, or whether it has been discontinued. As a result, the timeline below is intentionally left empty rather than inferred.
Specifications
Sensing & Compute
- LLM integration
- Works with VLA / embodied models
- Tactile / force sensors
- Captures subtle force and motion patterns
Safety & Market
- Primary market
- Embodied AI data collection
- Country
- China
- Availability
- Status unknown
- Price
- $ 0