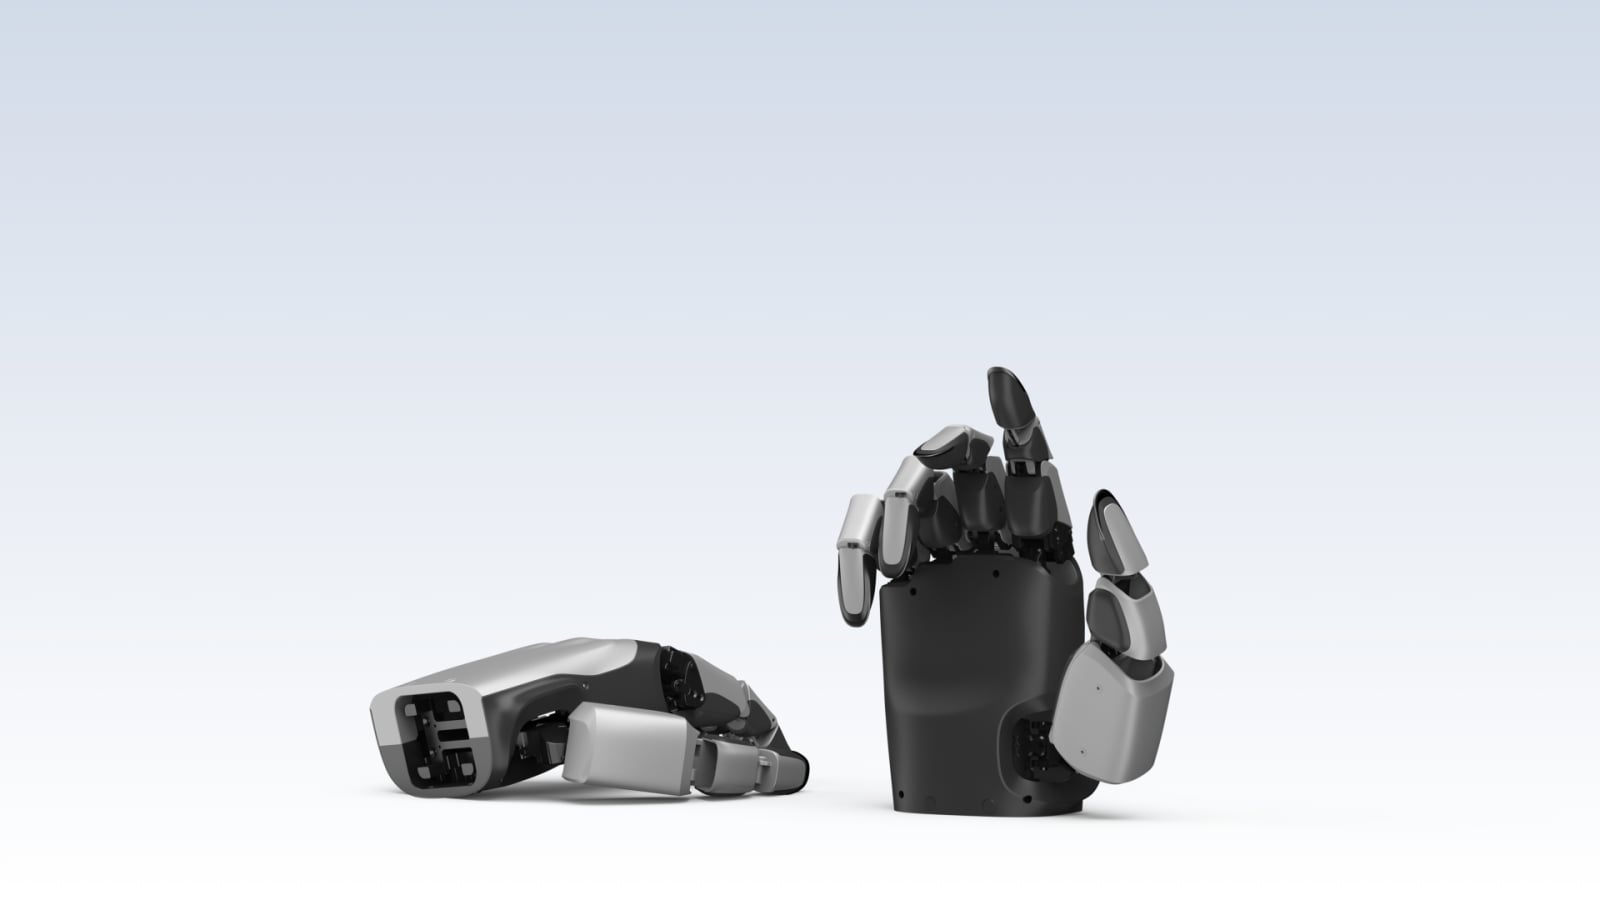
DexH13
$17,200
A four-finger dexterous robotic hand with tactile sensing, AI vision, and flexible motion for grasping and manipulation. It has 16 hand DoF and weighs 0.7 kg.
- Weight
- 0.7 kg
- Degrees of freedom
- 18
- Strength
- 5 kg
About
DexH13 is a dexterous robotic hand from PaXini Tech in China. It combines four-finger manipulation with tactile sensing, AI vision, and flexible motion for grasping and manipulation tasks. The model is described as having 16 hand degrees of freedom and a mass of 0.7 kg.
I do not have enough reliable historical information to place DexH13 on a dated development timeline or to identify a discontinuation year. The available details support a technical description of the product, but not a verified launch or milestone history.
Specifications
Body
- Weight
- 0.7 kg
- Degrees of freedom
- 18
- DoF (hands)
- 16
- Fingers
- 4
- Structural material
- metal alloys and engineering plastics/polymers
Motion
- Strength
- 5 kg
- Motor tech
- Hollow-cup motors drive the joints
- Gear tech
- 多连杆
Sensing & Compute
- CPU / GPU
- 内置 SoC,端侧算力支持
- Camera
- RGB / RGBD / 红外
- Connectivity
- EtherCAT or Modbus
- Tactile / force sensors
- Yes
Safety & Market
- Safe with humans
- 协作型
- Primary market
- robotics, industrial automation, and service tasks
- Country
- China
- Availability
- Status unknown
- Price
- $ 17 200