ORCA v1
Commercial$5,889
Open-source robotic hand with a tendon-driven structure and 17 active degrees of freedom. It is used for research, education, and creative robotics projects.
- Weight
- 1.3 kg
- Strength
- 12 kg
About
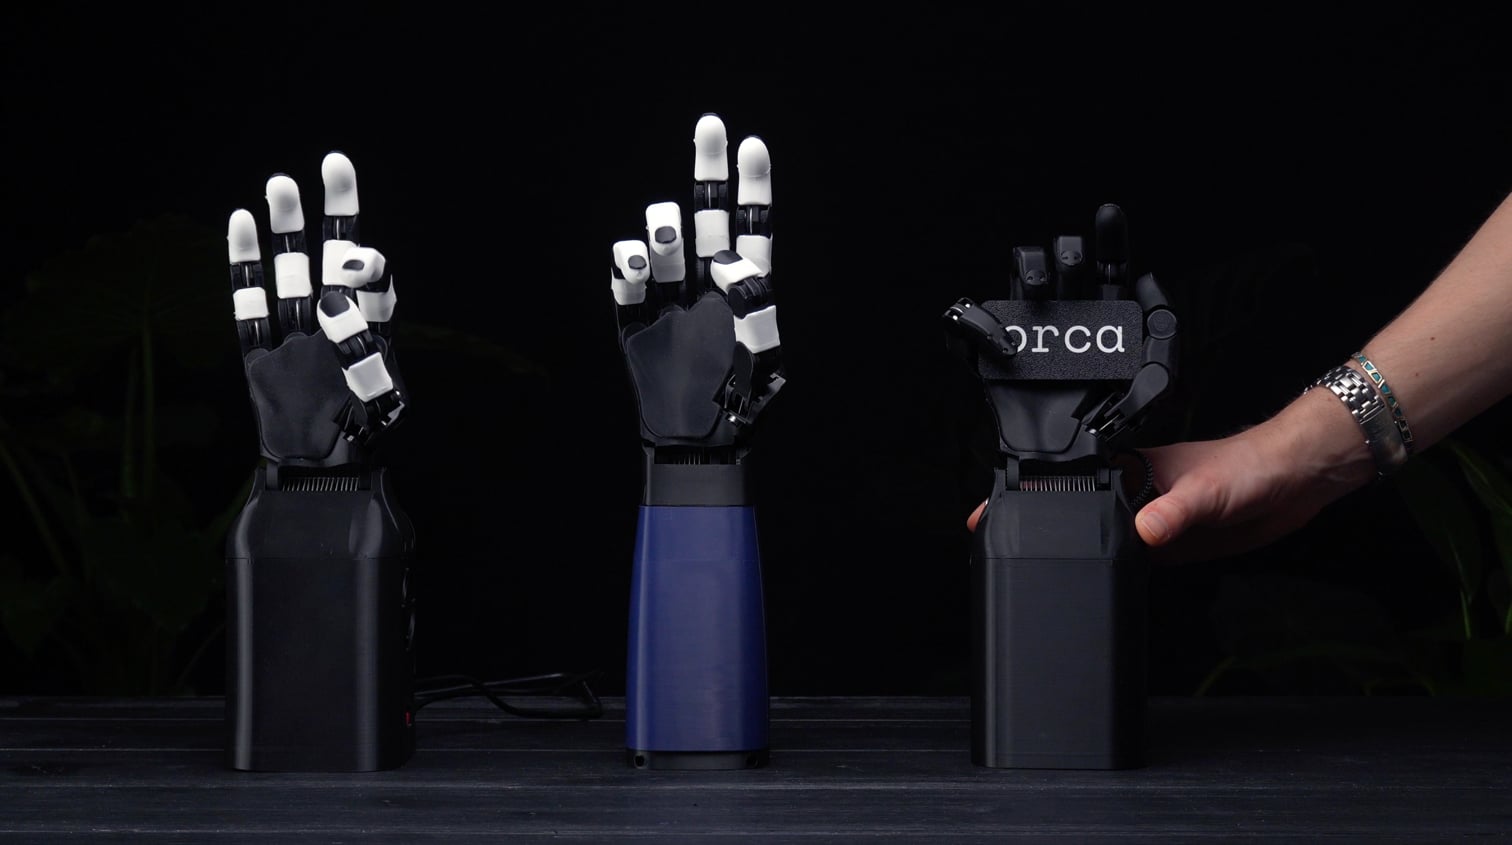
ORCA v1 is an open-source robotic hand developed by the Soft Robotics Lab at ETH Zürich and associated with ORCA Hand. It uses a tendon-driven structure and provides 17 active degrees of freedom, making it a flexible platform for research and education.
The hand has been used in robotics labs and creative projects where a modifiable, accessible hand design is more useful than a closed commercial product. As an open-source system, it has been shared as part of a broader effort to make robotic hand hardware easier to study, reproduce, and adapt.
Specifications
Body
- Weight
- 1.3 kg
- DoF (hands)
- 17
- Fingers
- 5
- Structural material
- 3D-printed parts (e.g. PLA or similar), covered with silicone cast skin for compliance and tactile grip
- Size
- anthropomorphic, roughly human-hand sized
- Shipping size
- anthropomorphic, roughly human-hand sized
Motion
- Strength
- 12 kg
- Motor tech
- Uses Dynamixel servos (e.g. XC330-T228T and XC430-T240BB-T)
- Gear tech
- Tendon-driven structure
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- research, education, creative robotics projects
- Country
- Switzerland
- Availability
- Commercial
- Price
- $ 5 889
Timeline1
- 2024-01-01 · release~ORCA v1 is released
The open-source ORCA v1 robotic hand is published by the Soft Robotics Lab at ETH Zürich.