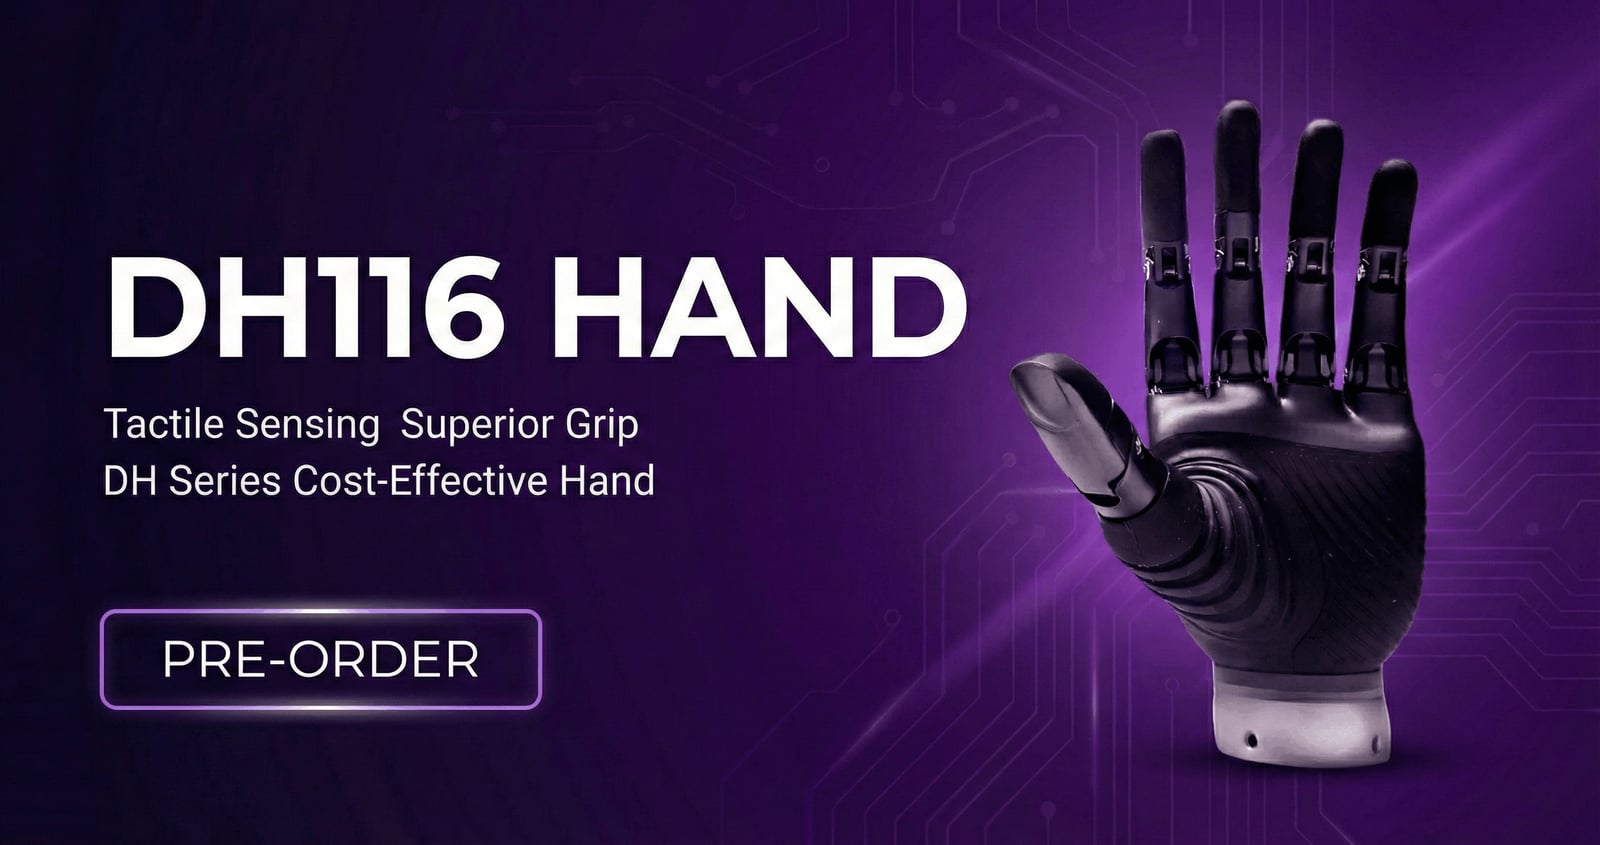
DH116
Commercial$3,100
Humanoid robotic hand for robotics and research applications, built for precise object manipulation. It has 11 DoF in the hand and weighs 0.49 kg.
- Weight
- 0.5 kg
- Degrees of freedom
- 11
- Strength
- 30 kg
About
I don’t have enough reliable information in my knowledge base to reconstruct a verified history for OpenDroids DH116. I can confirm only the basic description provided: it is a humanoid robotic hand for robotics and research applications, with 11 degrees of freedom and a mass of 0.49 kg.
Because I can’t verify its announcement, release, or any later lifecycle events from my training data, I’m leaving the timeline empty rather than guessing. If you can share a source document, brochure, or paper, I can turn that into a proper chronology.
Specifications
Body
- Weight
- 0.5 kg
- Degrees of freedom
- 11
- DoF (hands)
- 11
- Fingers
- 5
- Structural material
- Aluminum alloy and high-strength composites (assumed)
- Shipping size
- 128mm width x 280mm length x 125mm depth
Motion
- Strength
- 30 kg
- Motor tech
- Frameless Torque Motors
Sensing & Compute
- Connectivity
- Standard communication interfaces
- Tactile / force sensors
- Yes
Safety & Market
- Safe with humans
- Collaborative Control
- Primary market
- robotics and research applications
- Country
- USA
- Availability
- Commercial
- Price
- $ 3 100