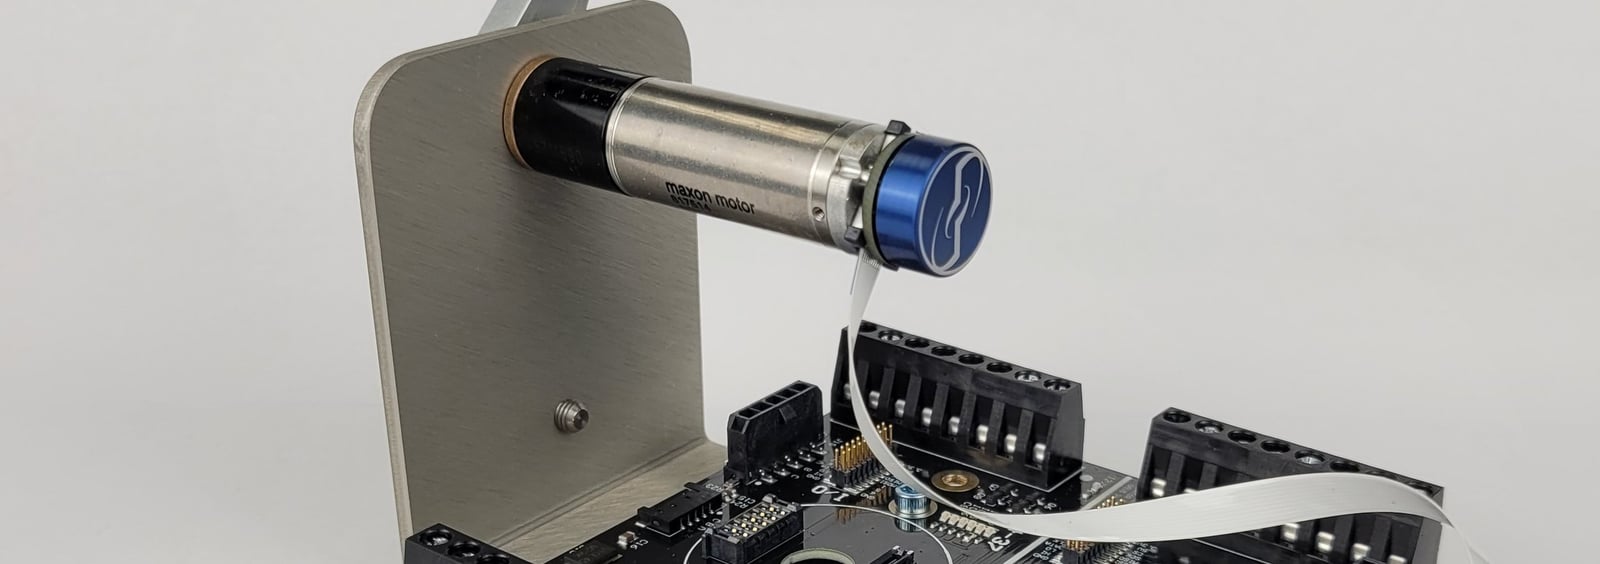
Puck®
CommercialActive since 1999
Motor controllers for OEM, high-speed, and high-payload applications, with onboard magnetic encoder, dual iSense control, CANopen communication, and daisy-chain wiring.
About
Barrett Technology, LLC introduced the Puck motor controller family as part of its work on compact actuation and control hardware for robotic systems. The Puck was designed for OEM and research uses, combining motor control, sensing, and network communication in a small module that could be integrated into larger robot assemblies.
Over time, Barrett expanded the Puck line to support higher current and higher payload applications, while keeping the same general architecture of onboard encoder feedback, dual current sensing, CANopen communication, and daisy-chain wiring. It became a common building block in Barrett’s own robotic platforms and in third-party systems that needed distributed motor control.
Specifications
Body
- Size
- P4-16: 1.2 cubic cm, 6 mm tall, 16 mm diameter; P4-37: 12.5 cubic cm
Motion
- Motor tech
- Space-Vector Commutation
Sensing & Compute
- CPU / GPU
- 32-bit floating point processor
- Connectivity
- High speed CANopen communication; 5-wire bus topology (2xCAN, Bus Voltage, 12V, GND); up to 31 controllers per bus
- Tactile / force sensors
- Dual iSense current sensor
Safety & Market
- Primary market
- OEM application; high-speed and high-payload applications; motor control
- Availability
- Commercial
Timeline4
- 2008-01-01 · milestone~High-payload variants expand
Barrett extends the product family toward higher-speed and higher-payload applications.
- 2003-01-01 · milestone~Networked daisy-chain wiring appears
Puck controllers adopt CAN-based communications and daisy-chain wiring for multi-axis systems.
- 2000-01-01 · milestone~Puck supports OEM integration
The controller is positioned for OEM use in modular robotic systems.
- 1999-01-01 · milestone~Puck controller family debuts
Barrett Technology introduces the Puck line for compact robotic motor control.