Robot Perception and Learning Lab· Mar 9, 2026
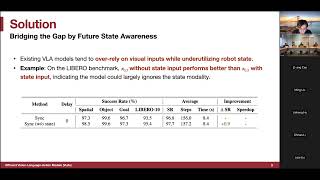
VLASH: Real-Time VLAs via Future-State-Aware Asynchronous inference - Jiaming Tang 03/09/2026
Jiaming Tang, an MIT PhD student researching efficient robotics and large models, presents VLASH at the Robot Perception and Learning Lab, explaining how future-state-aware asynchronous inference can make vision-language-action policies respond faster.