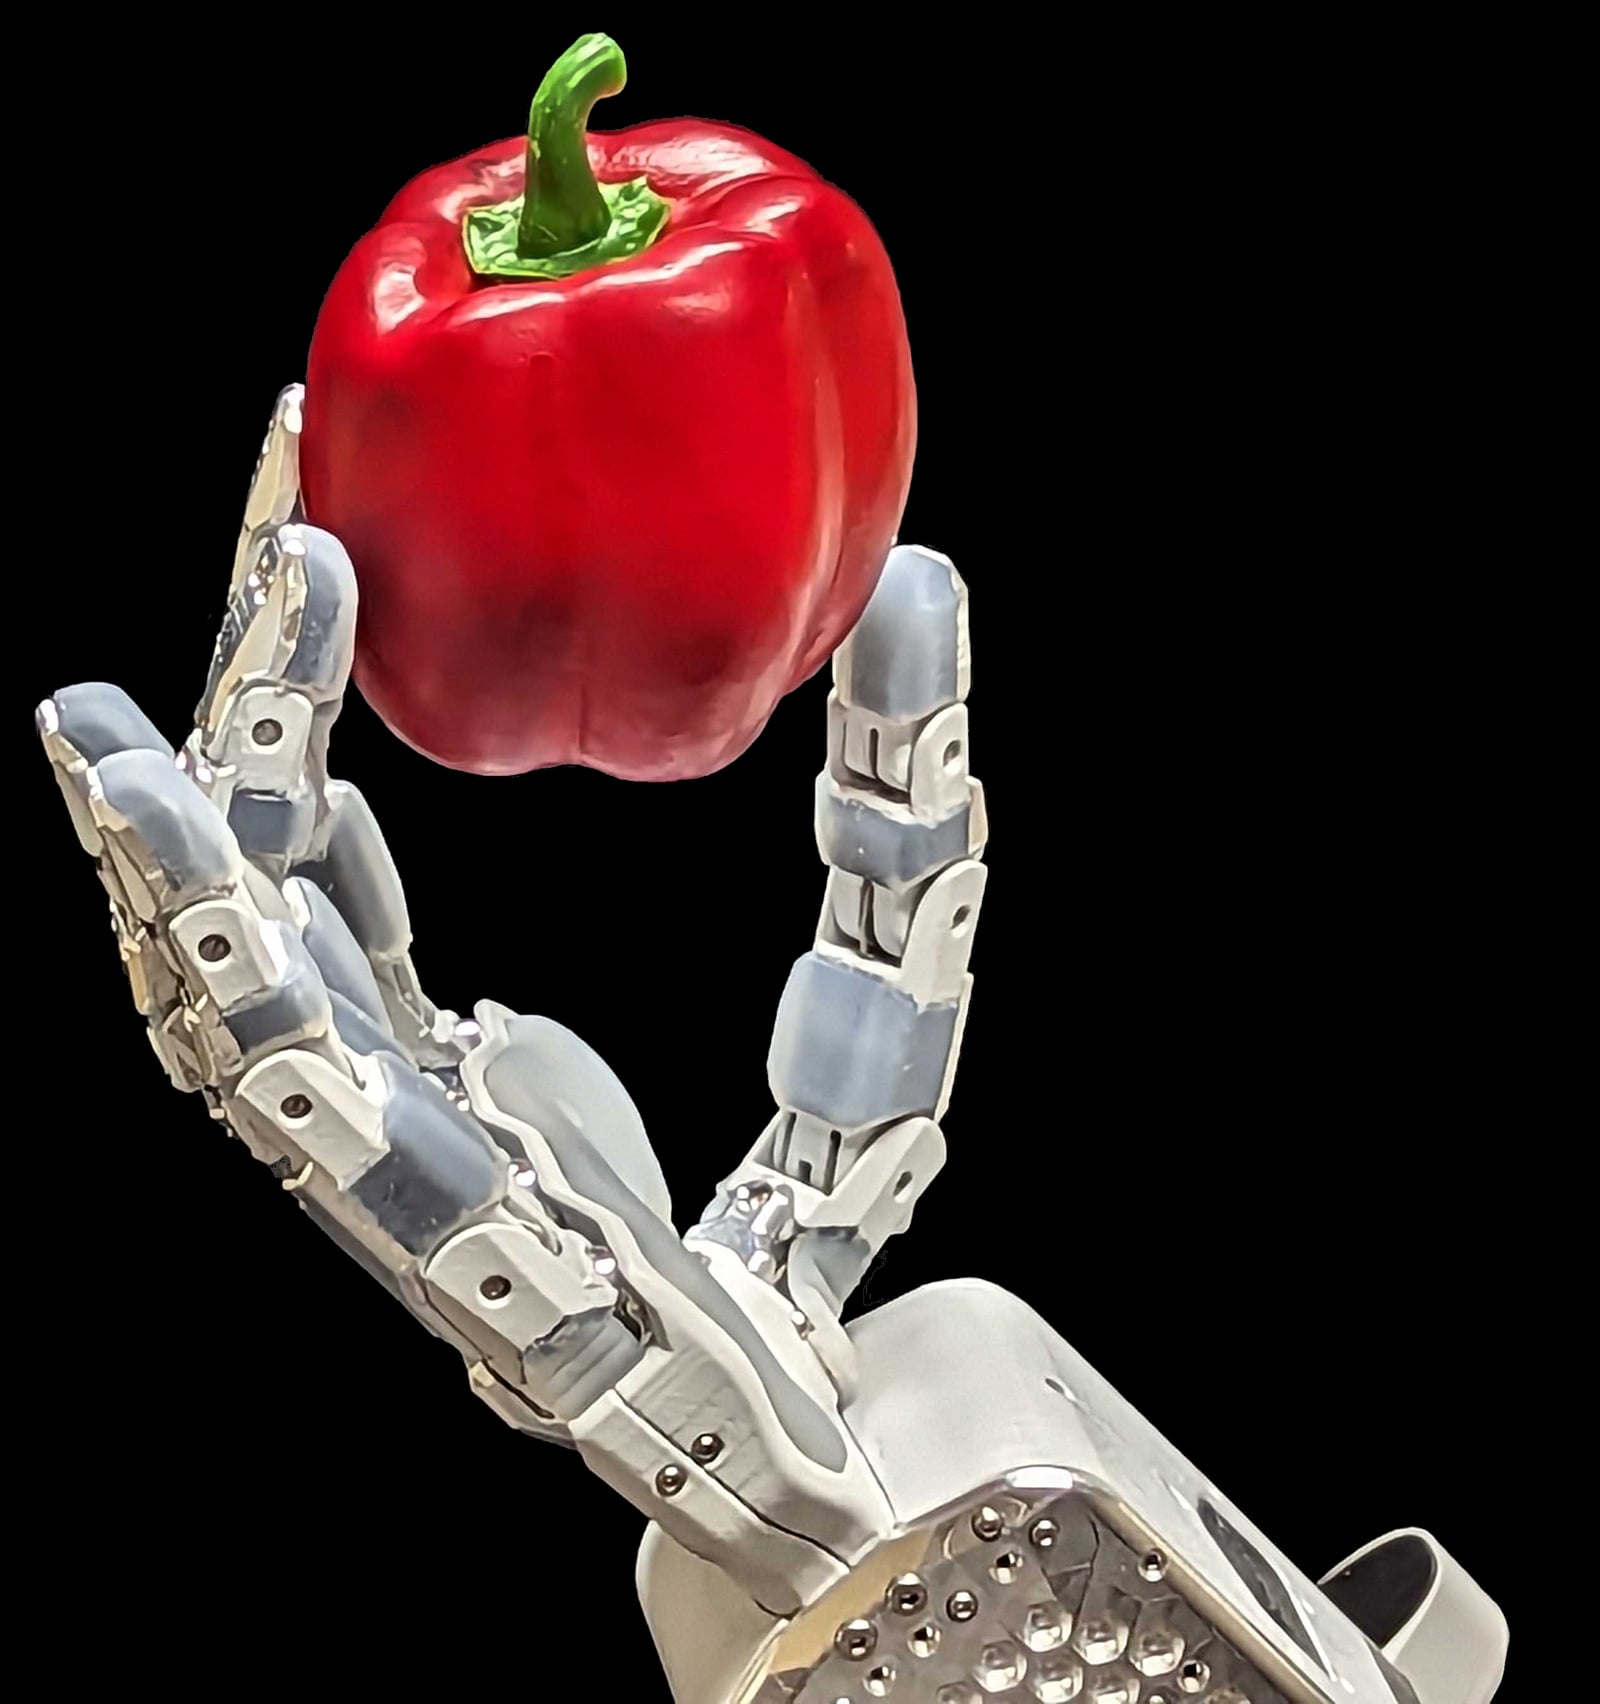
A compact robotic hand with 20 degrees of freedom for industrial automation, teleoperation, and humanoid robotics.