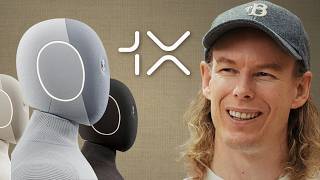
Børnich says NEO weighs 30 kg and can lift 70 kg, with dexterous hands and movement ranging from walking to crawling. He prioritizes a lightweight, low-energy design with a soft exterior and no pinch points, so the robot can work safely around people.
Børnich argues that human-shaped robots can learn from knowledge expressed through human language, video, and demonstrations. 1X operators teach robots by doing tasks through VR teleoperation, sometimes paired with motion capture. He sees legs as tools for repositioning the body during manipulation, such as bracing against a cupboard or reaching under a couch, rather than simply for walking on stairs.
Børnich measures useful work by the cost of providing 30 minutes of labor comparable to a person's, including work done through a mix of AI and teleoperation. He favors starting in homes, where imperfect results may still help, and gathering varied task data to build recovery and common-sense skills before tackling stricter manufacturing work. He ranks data variety first, collection quality second, and volume third.
1X trains an end-to-end network that maps sensor and robot-state inputs to actions, without separate modules for object recognition, mapping, or grasp planning. Børnich says a complex task can sometimes be learned from 10 to 50 real-world examples, while simulation may require millions and can struggle with contact, clothing, and human behavior. The company also uses its collected data to build predictive world models for planning.
Børnich describes NEO as designed for safe contact through low inertia, compliant joints, and an outer structure that absorbs impact. He contrasts this with geared industrial robots, whose moving parts can carry substantial energy and resist being pushed away. He says different settings call for different machines: factories still benefit from fast, accurate industrial robots, while humanoids suit varied environments where they must adapt to people and objects.
Briefs summarise talks and interviews; timestamps open the video at that moment. Claims in a talk are the speaker's own.
Bernt Børnich, CEO of 1X Technologies, explains why the company designed its Neo humanoid for homes and discusses its capabilities, pricing, teleoperation, safety, and path toward autonomy with Wall Street Journal host Joanna Stern.
Peter H. Diamandis talks with 1X Technologies founder and CEO Bernt Børnich and investor Dave Blundin at 1X’s Palo Alto facility about building humanoid robots for homes, learning through real-world use, and the manufacturing and safety challenges ahead.
Relentless host interviews Bernt Børnich, founder and CEO of 1X, about scaling humanoid robot manufacturing, learning from deployments, and building generally capable home robots.
Bloomberg Originals host and narrator, with 1X founder Bernt Børnich, UC Berkeley professor Ken Goldberg, GXO’s Patrick Kelleher, and other robotics, industry, and labor experts, examines humanoid robots’ potential and the hurdles they face in factories, warehouses, homes, and hospitals.
Bernt Børnich, founder and CEO of 1X, talks with Going Direct’s host about humanoid robots, robot learning, safety, manufacturing and 1X’s plans for Neo.