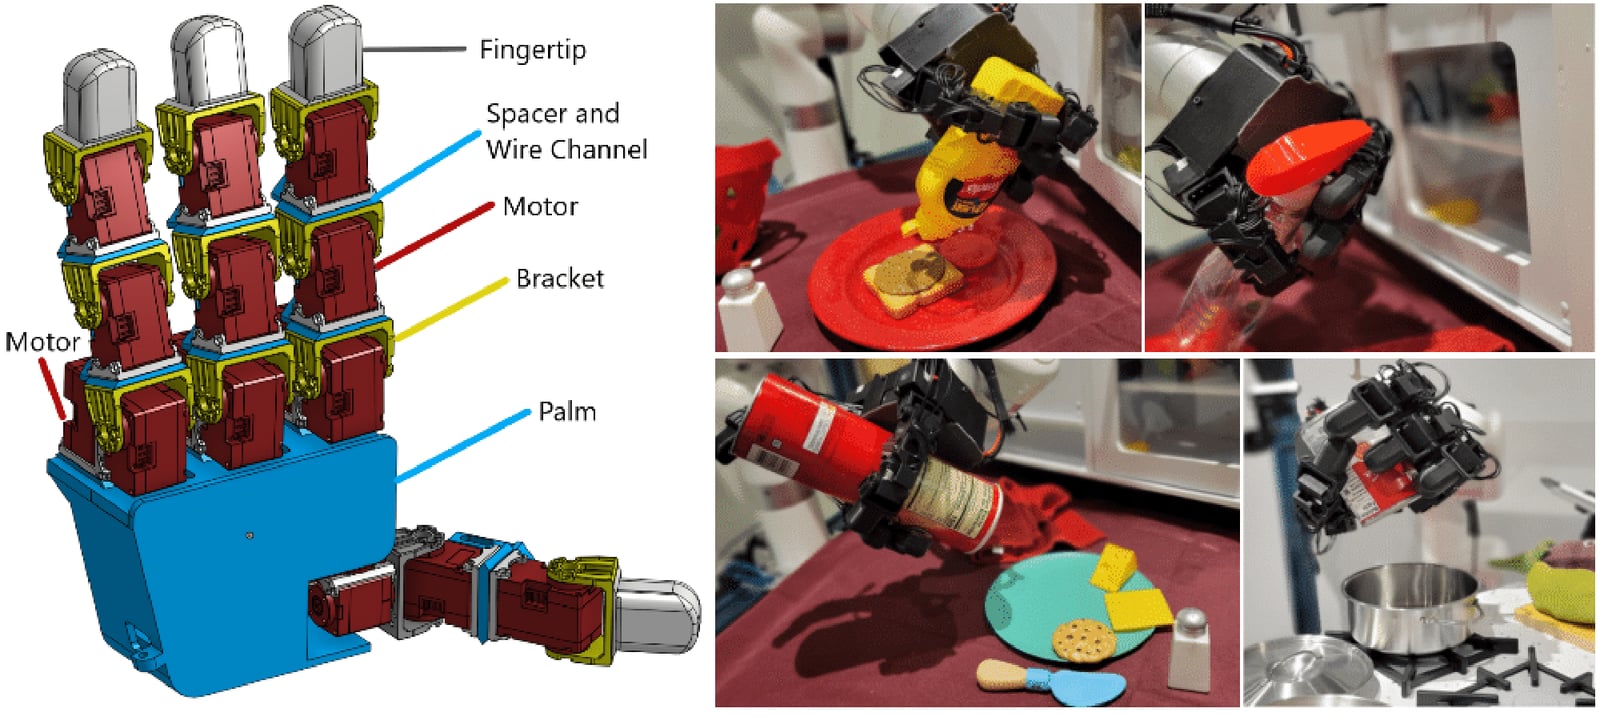
LEAP Hand
CommercialActive since 2023$2,000
A research-focused robotic hand for advanced manipulation tasks, with dexterity and tactile sensing. It is positioned as an affordable option.
- Weight
- 0.9 kg
- Strength
- 2 kg
About
LEAP Hand is a robotic hand developed at Carnegie Mellon University for research in dexterous manipulation. It was introduced as a compact hand platform intended to make advanced manipulation studies more accessible, while still supporting sensing and control experiments that depend on hand-level dexterity.
The project emphasized affordability and repeatability, with the hand designed for researchers who need a capable platform without the cost of many commercial anthropomorphic hands. LEAP Hand has been used in work on grasping, in-hand manipulation, and tactile or contact-rich interaction, placing it in the broader trend of open and research-oriented manipulation hardware.
Specifications
Body
- Weight
- 0.9 kg
- DoF (hands)
- 16
- Fingers
- 5
- Structural material
- 3D-printed polymers + metal components
Motion
- Strength
- 2 kg
- Motor tech
- Servo motors
Sensing & Compute
- Tactile / force sensors
- Yes
Safety & Market
- Primary market
- Research / advanced manipulation
- Country
- US
- Availability
- Commercial
- Price
- $ 2 000
Timeline2
- 2023-01-01 · release~LEAP Hand is released
Carnegie Mellon University introduces LEAP Hand as a research robotic hand for dexterous manipulation.
- 2023-01-01 · milestone~Project emphasizes affordable hand research
The hand is positioned as a lower-cost platform for manipulation and tactile-sensing experiments.